
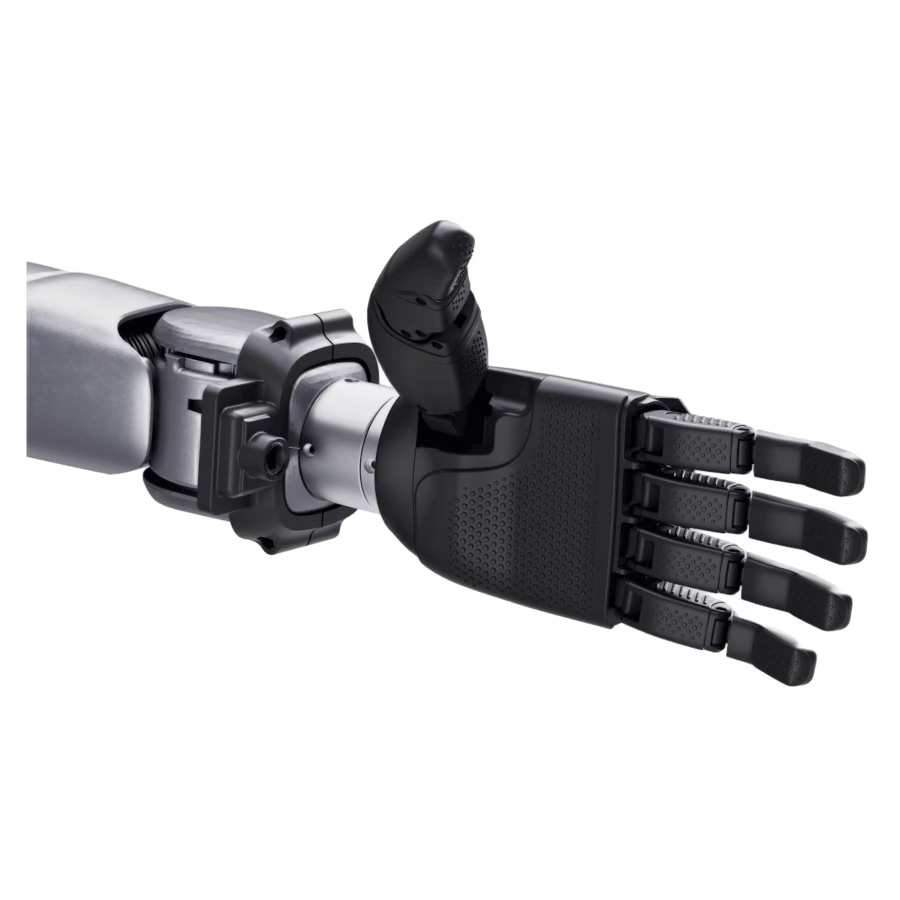
The Inspire E2 is a robotic hand with 6 degrees of freedom, 12 joints and 17 tactile sensors. It weighs approximately 800 g and provides fingertip repeatability of ±0.20 mm. Gripping force is 30 N for the thumb and 28 N for the four fingers, with a hand closure time of 0.8 seconds.
The tactile sensors offer a sensing range of 0–30 N and an accuracy of ≤ 5% of full scale. A wrist-mounted RGB camera with 1920 × 1080-pixel resolution is included, together with a dedicated camera bracket, cables and other accessories.
The Inspire E2 combines 6 degrees of freedom and 12 joints with tactile sensing. Its 17 tactile sensors measure within a range of 0–30 N, with an accuracy of ≤ 5% of full scale. The hand achieves fingertip repeatability of ±0.20 mm and closes in 0.8 seconds.
Thumb lateral swing and bending speeds both exceed 130°/s, while the four fingers achieve bending speeds above 200°/s. The hand operates on 24 V (+10%), with a static current of 0.25 A and a maximum current of 4 A. An included wrist-mounted RGB camera provides a 130° diagonal field of view.