
Humanoid
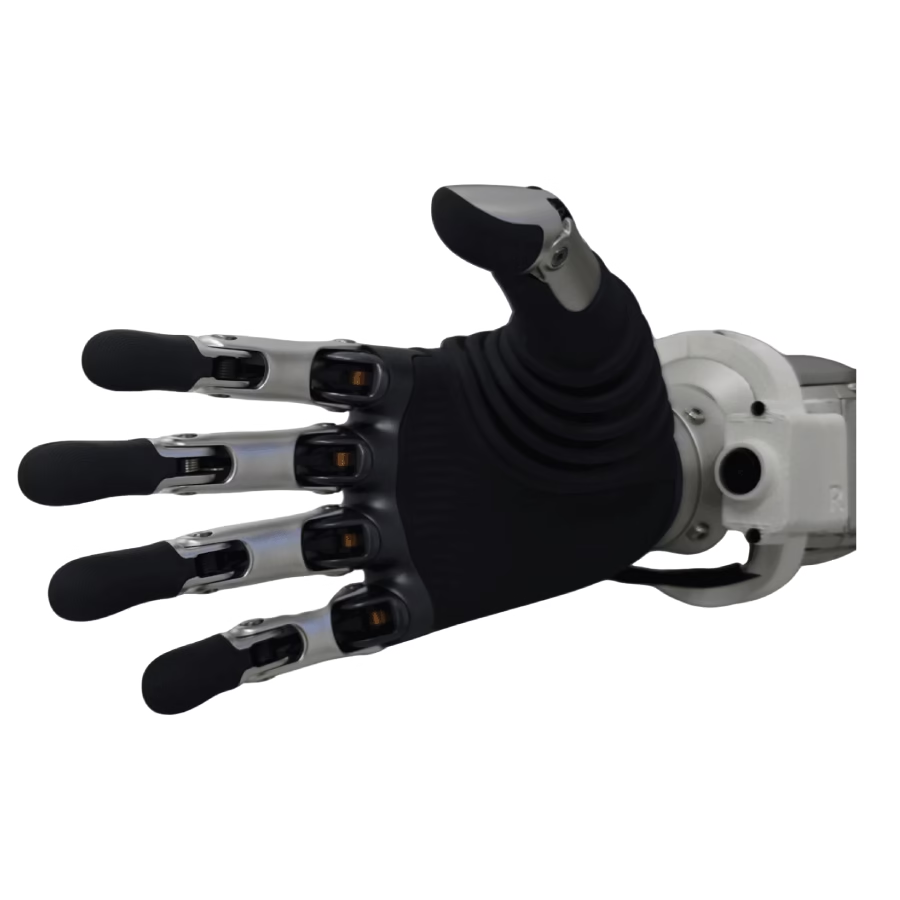
The BrainCo Revo 2 Basic is a bionic robotic hand weighing 383 g, with a whole-hand grip force of 50 N and a single-finger pinch force of 15 N. It offers repeatability of 0.1° and measures 160 mm from the middle fingertip to the palm base.
Humanoid
The BrainCo Revo 2 Tactile is a bionic robotic hand with 6 degrees of freedom, 11 joints and built-in sensing for pressure, friction, direction and proximity. It weighs 383 g and provides a whole-hand grip force of 50 N, a single-finger pinch force of 15 N and repeatability of 0.1°.
Humanoid
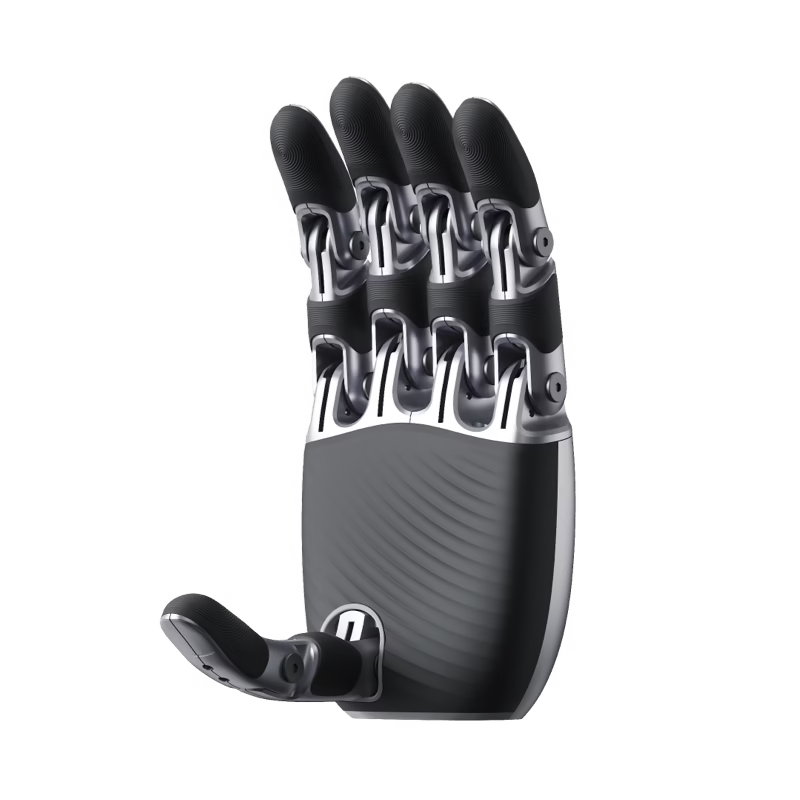
The DEX 2/5 is a tendon-driven robotic hand with 2 degrees of freedom and 10 joints. Eight joints serve the four fingers, while the thumb has 2 joints. The hand weighs approximately 365 g and measures approximately 151 × 67 × 70 mm.
Humanoid
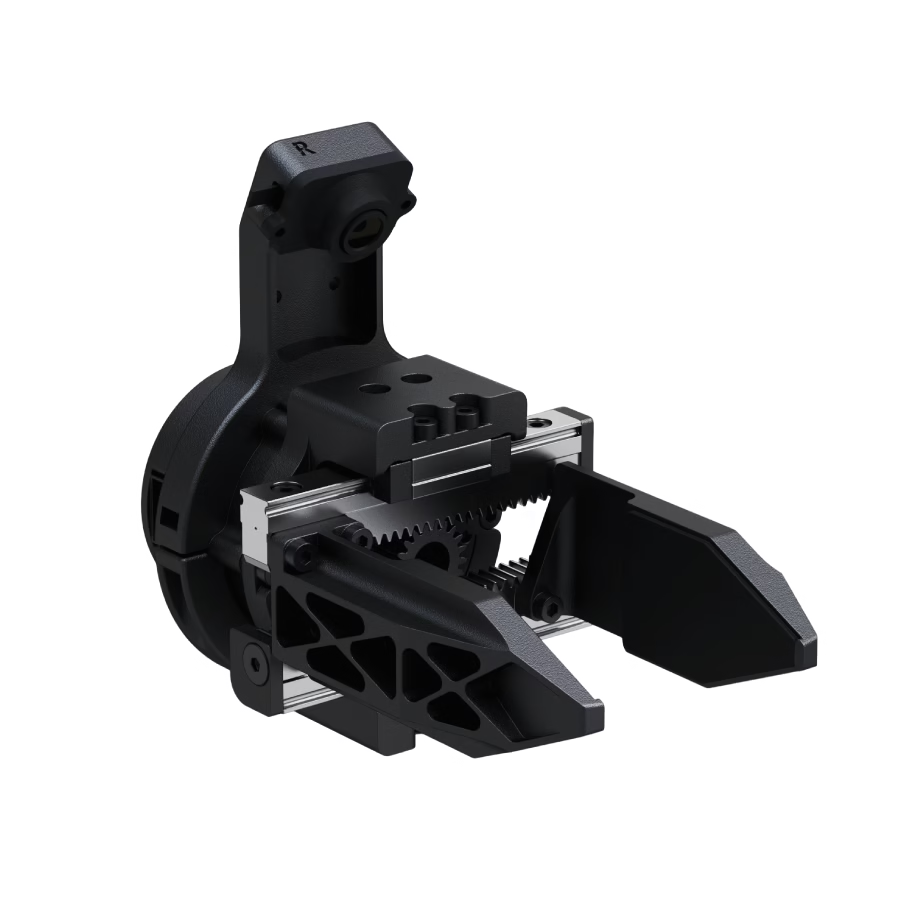
The Dex1-1 Gripper Plus Version includes an RGB camera with a 160° field of view and a dedicated camera bracket. It supports further development and customisation through a provided robot development interface.
Humanoid
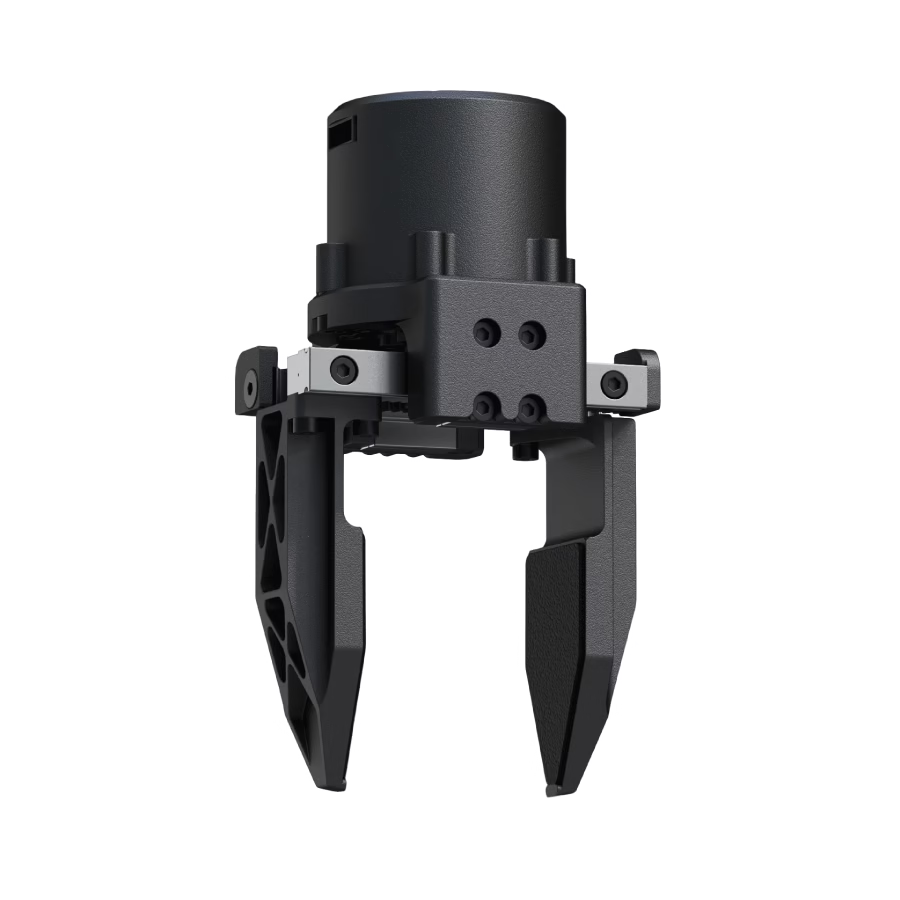
The Dex1-1 Gripper Standard Version supports further development and customisation through a provided robot development interface. The package includes one gripper, an RS485-to-USB adapter board, cables and other accessories.
Humanoid
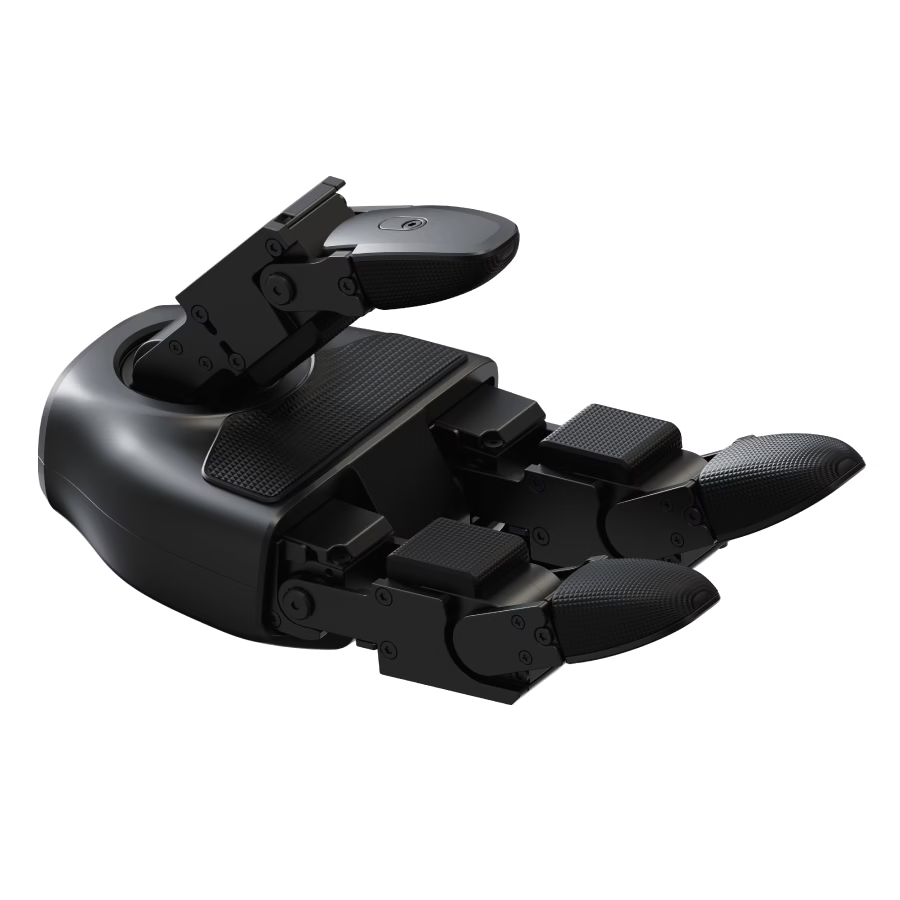
The Dex3-1 is a force-controlled three-finger robotic hand with 7 degrees of freedom: 3 for the thumb and 2 each for the index and middle fingers. It weighs 650 g and measures 175 × 88 × 77 mm.
Humanoid
The Dex3-1 Tactile is a force-controlled three-finger robotic hand with 33 tactile sensors and 7 degrees of freedom. The thumb provides 3 degrees of freedom, while the index and middle fingers each provide 2. The hand weighs 650 g and measures 175 × 88 × 77 mm.
Humanoid
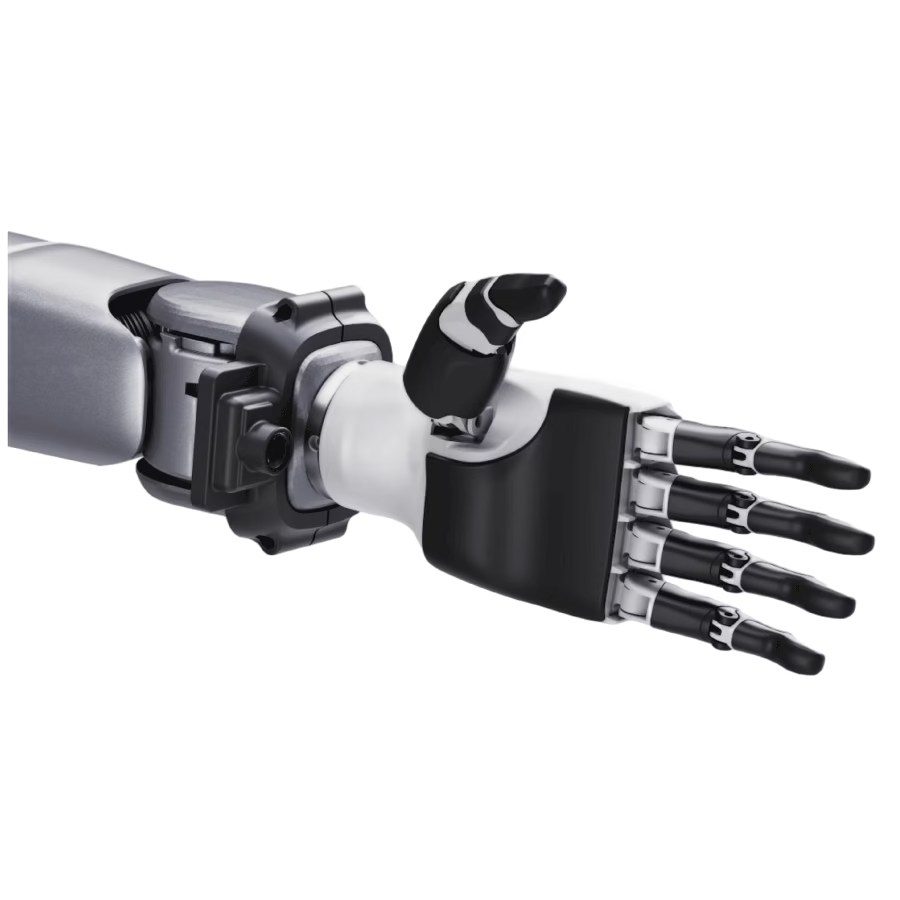
The Inspire DFQ is a robotic hand with 6 degrees of freedom, 12 joints and a positioning repeatability of ±0.20 mm. Maximum gripping force is 6 N for the thumb and 4 N for the four fingers, with a gripping force resolution of 0.50 N.
Humanoid
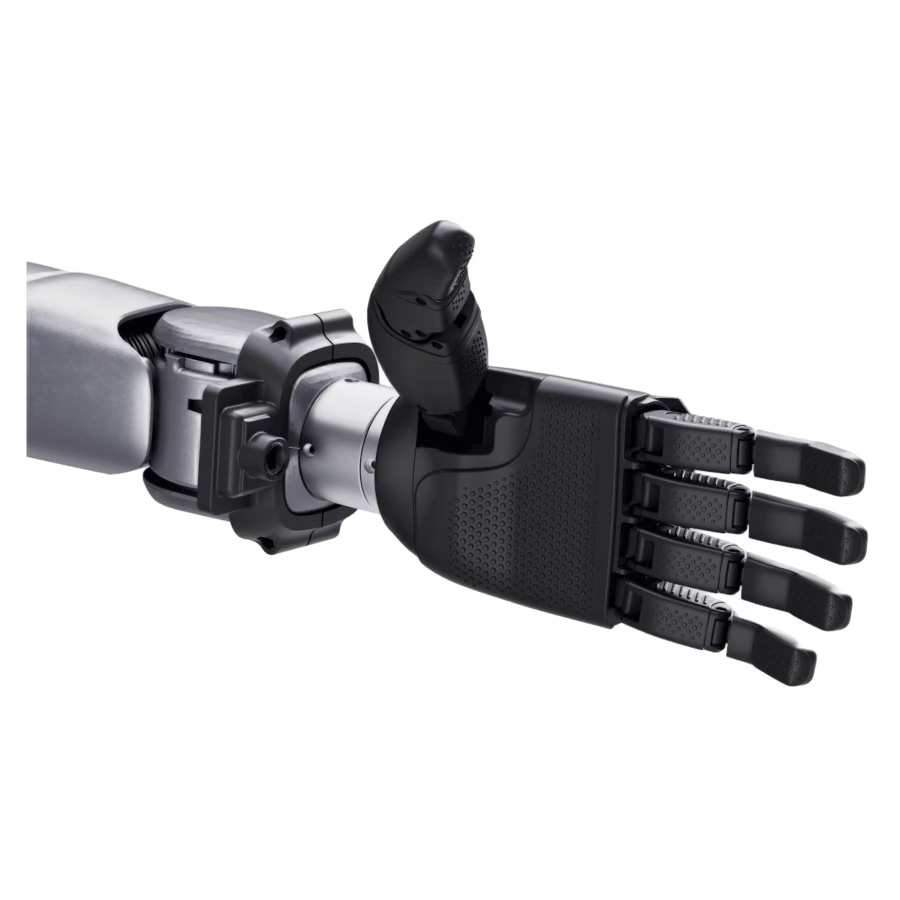
The Inspire E2 is a robotic hand with 6 degrees of freedom, 12 joints and 17 tactile sensors. It weighs approximately 800 g and provides fingertip repeatability of ±0.20 mm. Gripping force is 30 N for the thumb and 28 N for the four fingers, with a hand closure time of 0.8 seconds.
Humanoid
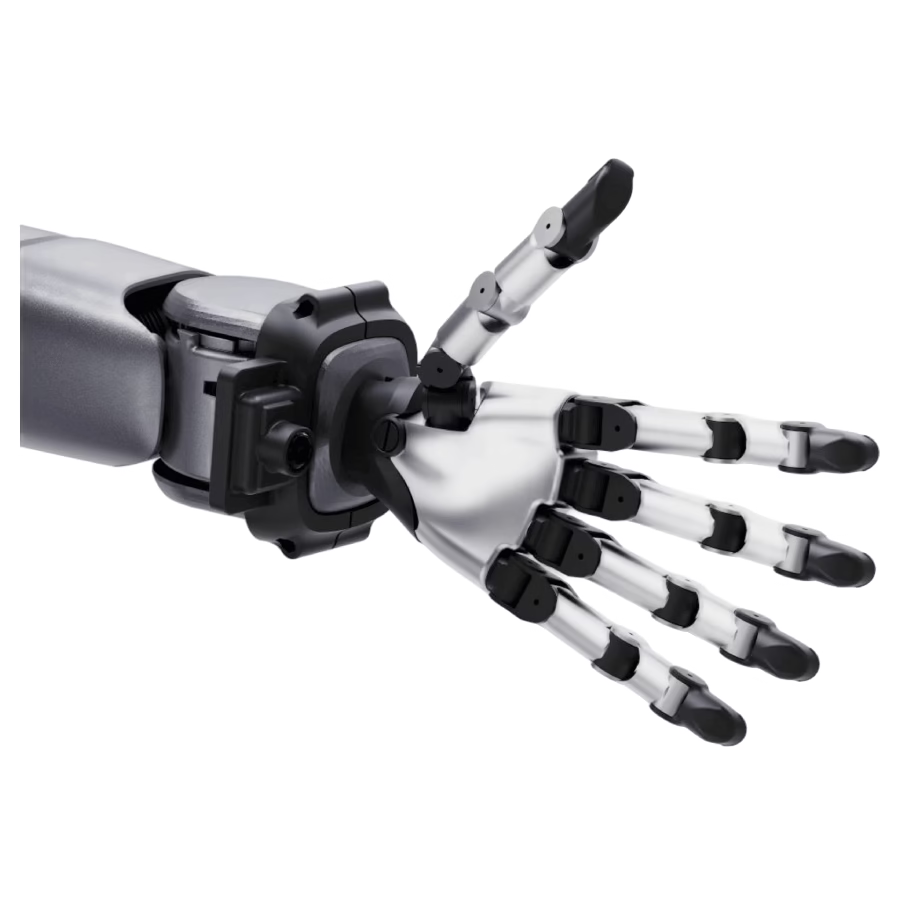
The Wuji Hand2 is a robotic hand with 20 active degrees of freedom, full opposition capability and lateral finger movement. Its direct-drive rotary joints are back-drivable, and MIT hybrid force/position control operates at 1,000 Hz across each of the 20 axes. Peak fingertip force is ≥ 15 N.