
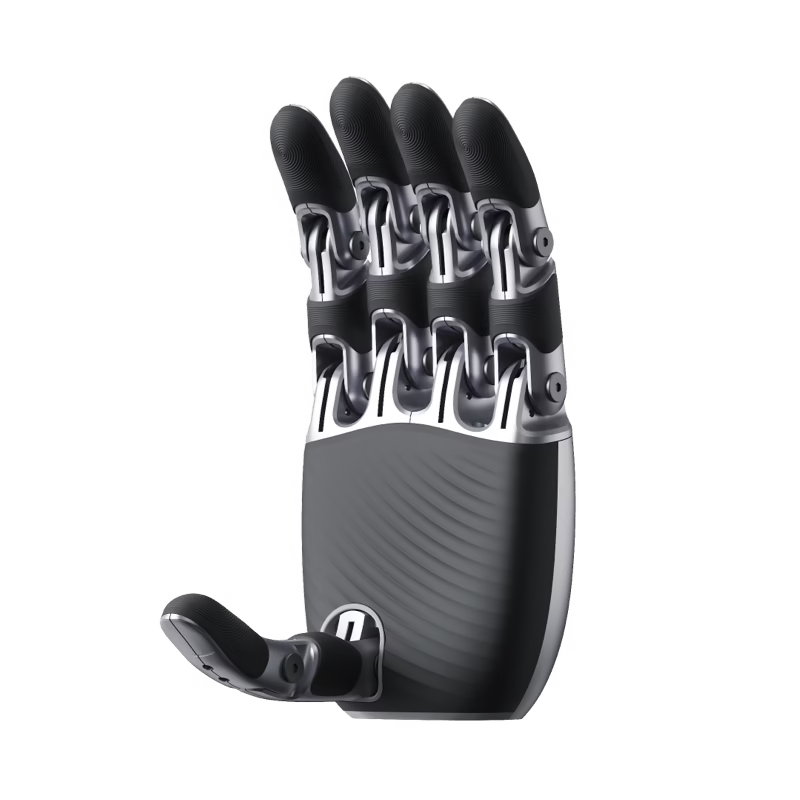
The DEX 2/5 is a tendon-driven robotic hand with 2 degrees of freedom and 10 joints. Eight joints serve the four fingers, while the thumb has 2 joints. The hand weighs approximately 365 g and measures approximately 151 × 67 × 70 mm.
Operating on 24–58 V, the DEX 2/5 provides a fingertip force of 10 N. This version has no tactile sensing. A robot development interface is provided to support further development and customisation.
The DEX 2/5 features a manufacturer-developed tendon-driven mechanism with 2 degrees of freedom distributed across a 10-joint hand. The four fingers have 8 joints in total, with a further 2 joints in the thumb. Its dimensions are approximately 151 × 67 × 70 mm, with a weight of approximately 365 g.
The hand delivers a fingertip force of 10 N and uses a 24–58 V power supply. It has no tactile sensing and supports further development through a provided robot development interface.