
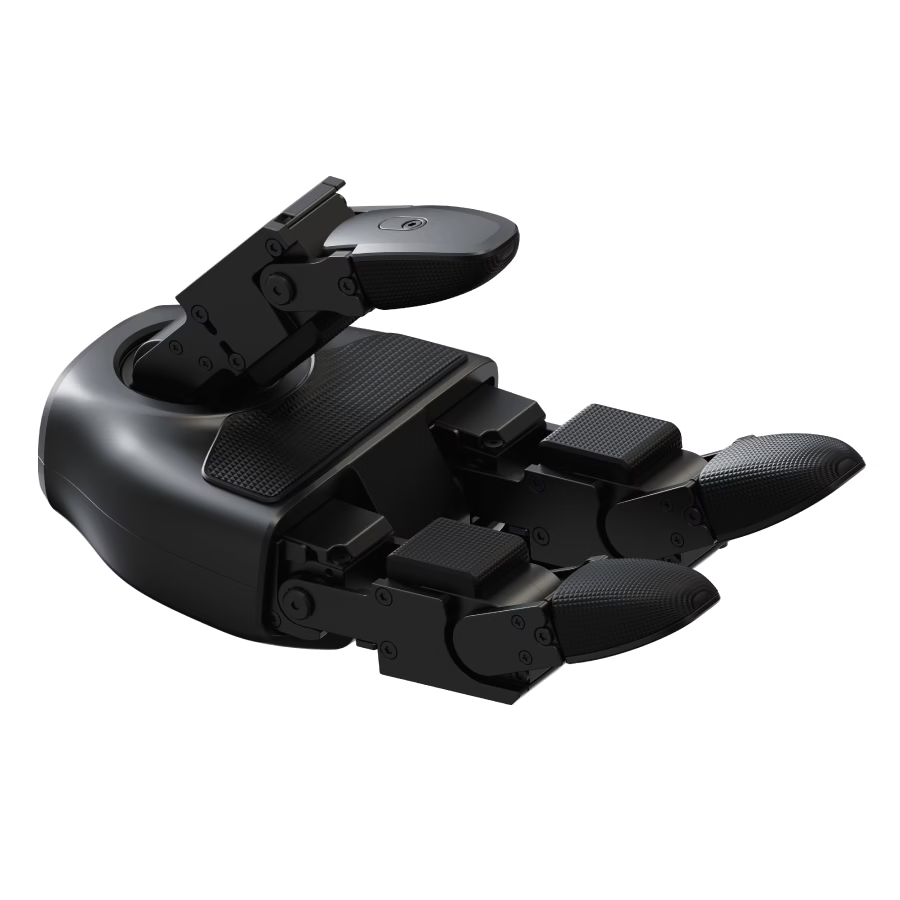
The Dex3-1 Tactile is a force-controlled three-finger robotic hand with 33 tactile sensors and 7 degrees of freedom. The thumb provides 3 degrees of freedom, while the index and middle fingers each provide 2. The hand weighs 650 g and measures 175 × 88 × 77 mm.
A wrist-mounted RGB camera is included, offering 1920 × 1080-pixel resolution and a field of view of 130° diagonally, 120° horizontally and 81° vertically. The package also includes a dedicated camera bracket, cables and other accessories.
The Dex3-1 Tactile combines force control with 33 tactile sensors in a three-finger design. Its 7 degrees of freedom are distributed across the thumb, index finger and middle finger, with 3, 2 and 2 degrees of freedom respectively. The hand measures 175 × 88 × 77 mm and weighs 650 g.
The included wrist-mounted RGB camera delivers images at 1920 × 1080 pixels. Its field of view covers 130° diagonally, 120° horizontally and 81° vertically. A dedicated mounting bracket, cables and other accessories complete the package.