
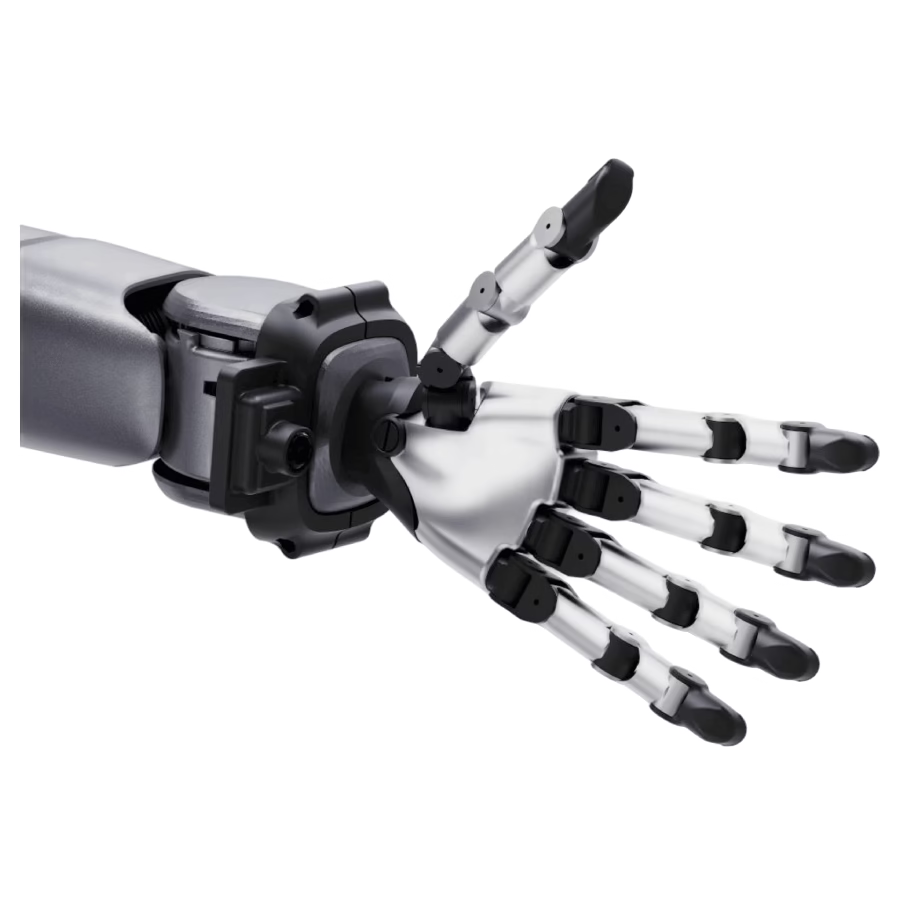
The Wuji Hand2 is a robotic hand with 20 active degrees of freedom, full opposition capability and lateral finger movement. Its direct-drive rotary joints are back-drivable, and MIT hybrid force/position control operates at 1,000 Hz across each of the 20 axes. Peak fingertip force is ≥ 15 N.
This version has no tactile sensing but provides force detection over a range of 0–30 N, with a sensitivity of 0.005 N. A wrist-mounted RGB camera with 1920 × 1080-pixel resolution is included, together with a dedicated camera bracket, cables and other accessories.
The Wuji Hand2 combines full opposition capability and lateral finger movement with 20 active degrees of freedom. Its back-drivable, direct-drive rotary joints use MIT hybrid force/position control, with communication via Gigabit Ethernet. The hand opens and closes at least 4 times per second, with joint backlash below 1°.
The hand’s skeleton measures approximately 185 × 80 × 40 mm and operates on 16–58 V DC. Force detection covers 0–30 N with a sensitivity of 0.005 N. The included wrist-mounted RGB camera offers a 130° diagonal, 120° horizontal and 81° vertical field of view.