
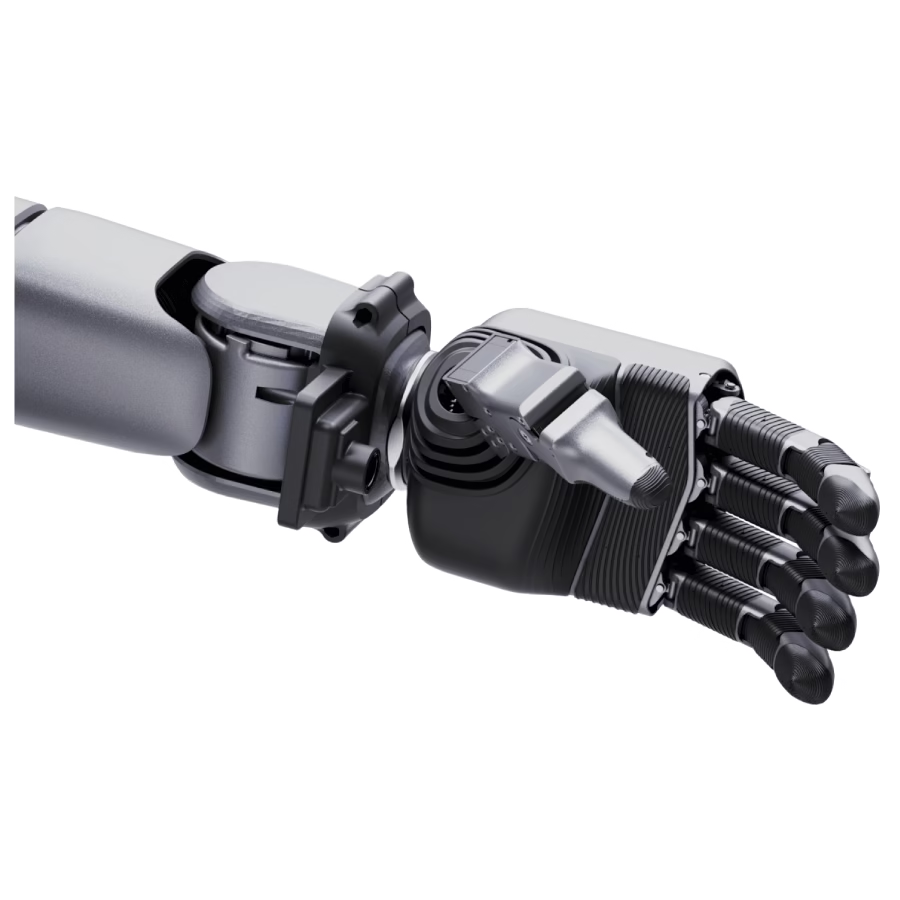
The Dex5-1 for H2 is a five-finger robotic hand with 16 active degrees of freedom: 4 for the thumb and 3 for each remaining finger. Its drive system combines 12 micro force-control composite transmission joints with 4 micro gear-driven joints, enabling proprioceptive feedback without tactile sensors.
The hand can grasp objects as small as 10 mm in diameter, with fingertip repeatability of ±1 mm and a fingertip force of 10 N. It communicates via USB 2.0 at 1,000 Hz. A wrist-mounted RGB camera, dedicated camera bracket, cables and other accessories are included.
The Dex5-1 is designed for H2 and provides 16 active degrees of freedom across five fingers. Twelve manufacturer-developed micro force-control composite transmission joints and four micro gear-driven joints provide feedback on joint mode, position, velocity and torque without requiring tactile sensors.
The thumb has 4 active degrees of freedom, while each remaining finger has 3, with an additional coupled joint movement. The hand delivers 10 N of fingertip force and ±1 mm fingertip repeatability. It operates on 24–60 V DC and includes a wrist-mounted RGB camera with 1920 × 1080-pixel resolution.