
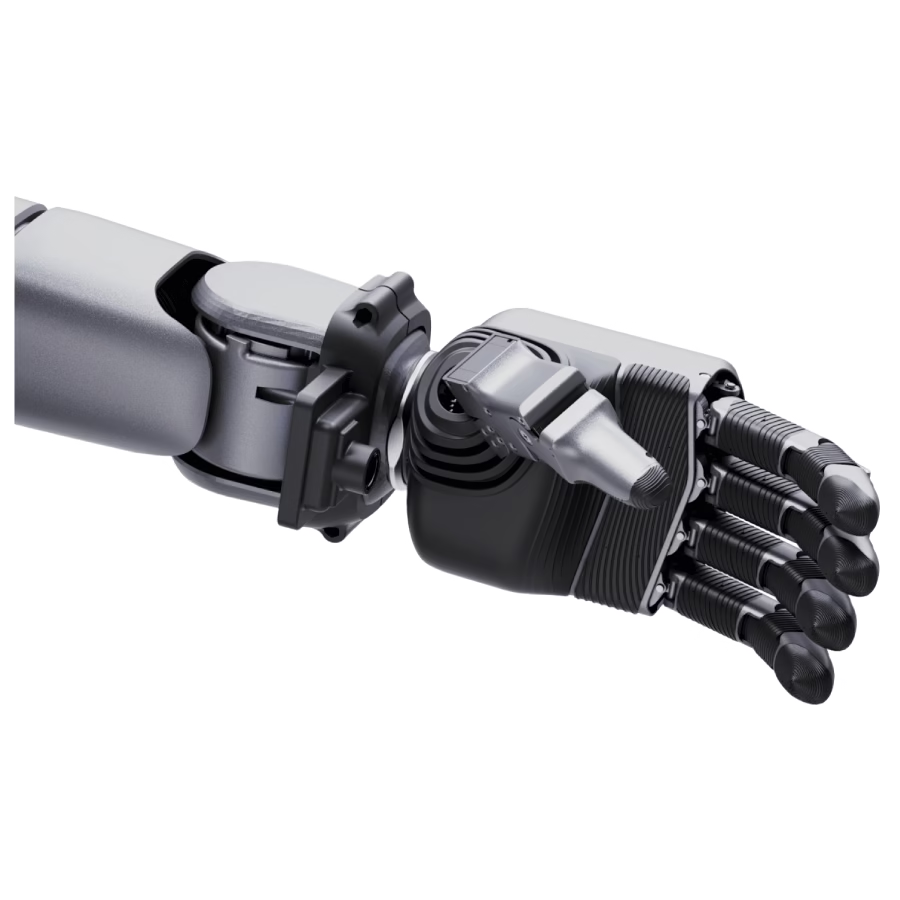
The Dex5-1P for H2 is a five-finger robotic hand that includes all Dex5-1 configurations and features, with the addition of 12 sensor arrays containing 94 pressure sensors. The sensors offer a sensing range of 10–2,500 g and a maximum non-destructive load tolerance of 20 kg.
The hand provides feedback on joint mode, position, velocity and torque. A wrist-mounted RGB camera is included, delivering 1920 × 1080-pixel images with a field of view of 130° diagonally, 120° horizontally and 81° vertically. A dedicated camera mounting bracket is also supplied.
The Dex5-1P builds on the Dex5-1 platform, retaining its configurations and features while adding pressure sensing through 12 sensor arrays. These arrays contain 94 pressure sensors with a sensing range of 10–2,500 g. The specified maximum load tolerance without damage is 20 kg; this value describes sensor tolerance rather than hand payload capacity.
Designed for H2, the hand returns joint mode, position, velocity and torque data. The included wrist-mounted RGB camera provides 1920 × 1080-pixel resolution and a 130° diagonal, 120° horizontal and 81° vertical field of view, with a dedicated mounting bracket.