H2 EDU-BrainCo Revo 3 U21T Tactile Version

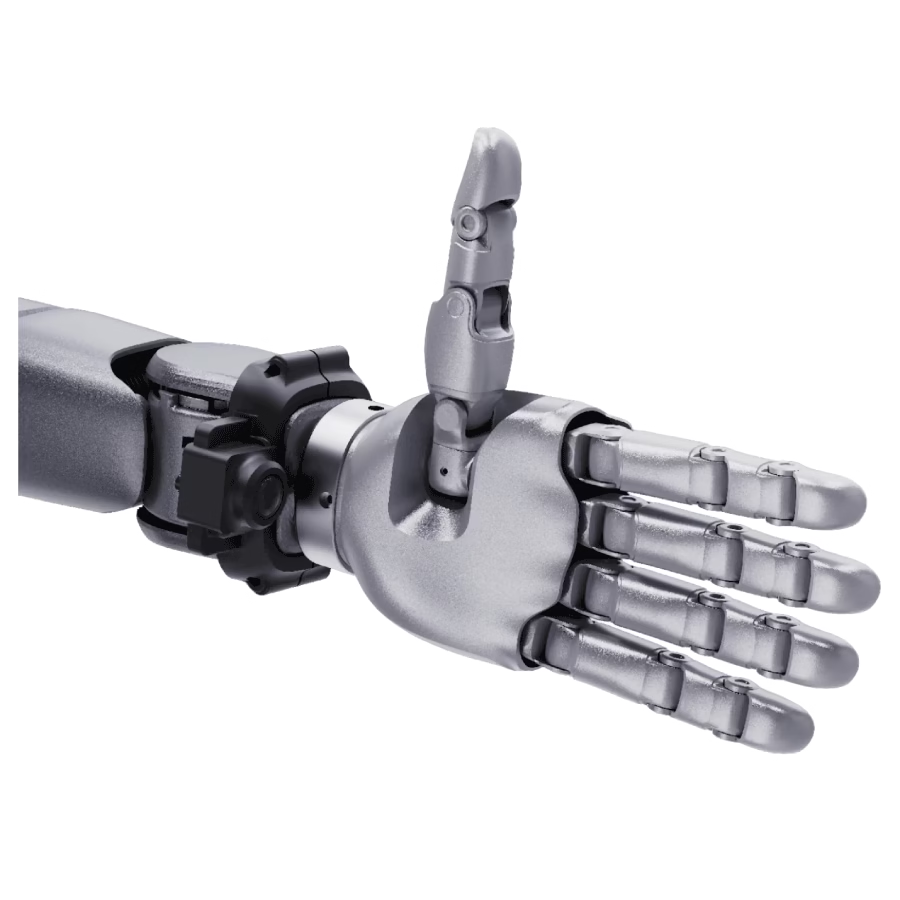
The BrainCo Revo 3 U21T for H2 EDU is a robotic hand with 21 active degrees of freedom, all fully direct-drive and back-drivable. Each of the four fingers has 4 degrees of freedom, while the thumb has 5. Active grip force is 70 N, with a maximum fingertip pinch force of 20 N.

A tactile sensor array covers the full palm, providing a sensing range of 0–25 N and a resolution of 0.01 N. The hand supports grasping diameters of 10–150 mm. A wrist-mounted RGB camera, dedicated camera bracket, cables and other accessories are included.

Requst a quote

Choose your accessories

Direct-Drive Robotic Hand for H2 EDU with Full-Palm Tactile Sensing

The BrainCo Revo 3 U21T combines 21 active degrees of freedom with a full-palm tactile sensor array. Its fully direct-drive, back-drivable joints provide motion repeatability of 0.1° and an opening and closing frequency of 3 Hz. The hand measures 215 × 105 × 50 mm.

All five fingers can touch the palm, supporting grasping diameters from 10 to 150 mm. The specified payload is 20 kg for the whole hand and 5 kg for the four fingers. The included wrist-mounted RGB camera delivers 1920 × 1080-pixel images with a 130° diagonal, 120° horizontal and 81° vertical field of view.

Included in the Package

  • 1 × BrainCo Revo 3 U21T dexterous robotic hand with tactile sensing for H2 EDU
  • 1 × wrist-mounted RGB camera
  • 1 × dedicated RGB camera bracket
  • Cables and other accessories

Technical Specifications

  • Designed for: H2 EDU
  • Active degrees of freedom: 21
  • Drive configuration: Fully direct-drive, back-drivable
  • Four fingers: 4 DOF per finger
  • Thumb: 5 DOF
  • Hand dimensions: 215 × 105 × 50 mm
  • Supply voltage: 12–80 V
  • Maximum current at 24 V: 10 A
  • Active grip force: 70 N
  • Maximum fingertip pinch force: 20 N
  • Whole-hand payload: 20 kg
  • Four-finger payload: 5 kg
  • Motion repeatability: 0.1°
  • Joint opening/closing frequency: 3 Hz
  • Finger movement: All five fingers can touch the palm
  • Minimum grasping diameter: 10 mm
  • Maximum grasping diameter: 150 mm
  • Tactile sensor configuration: Full-palm sensor array
  • Tactile sensing range: 0–25 N
  • Tactile sensing resolution: 0.01 N
  • RGB camera mounting position: Wrist
  • RGB camera resolution: 1920 × 1080 pixels
  • RGB camera field of view: 130° diagonal, 120° horizontal and 81° vertical