H2 Dedicated Dex5-1 Five-finger Dexterous Hand

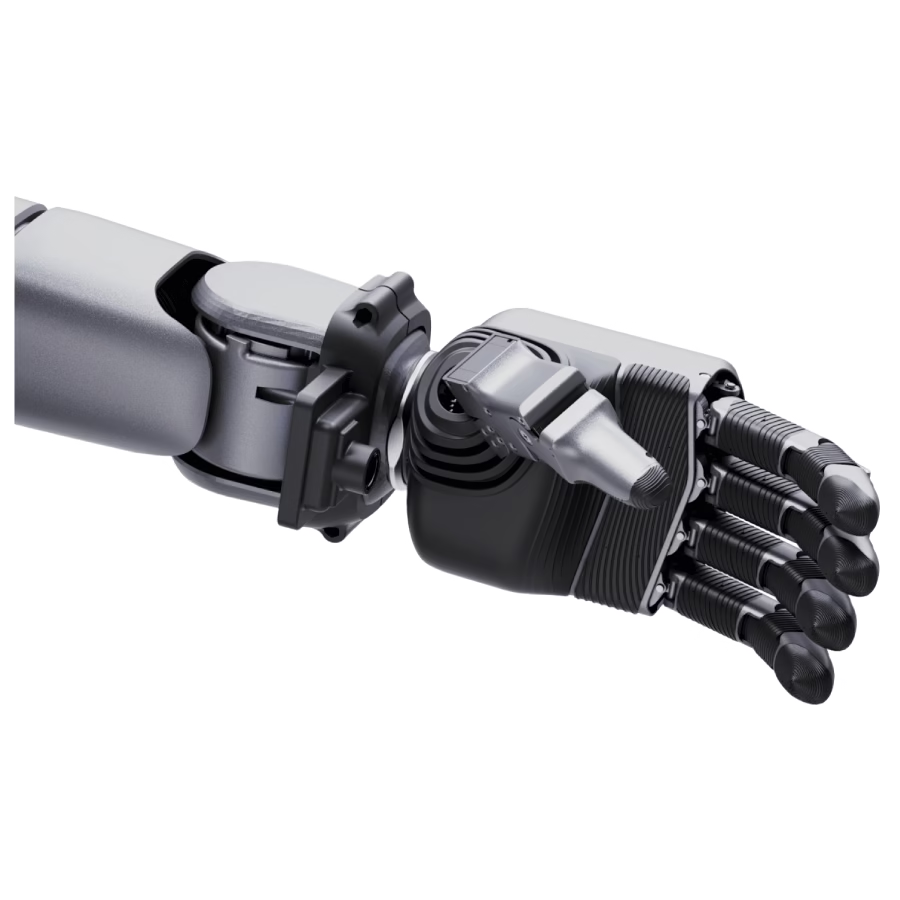
The Dex5-1 for H2 is a five-finger robotic hand with 16 active degrees of freedom: 4 for the thumb and 3 for each remaining finger. Its drive system combines 12 micro force-control composite transmission joints with 4 micro gear-driven joints, enabling proprioceptive feedback without tactile sensors.

The hand can grasp objects as small as 10 mm in diameter, with fingertip repeatability of ±1 mm and a fingertip force of 10 N. It communicates via USB 2.0 at 1,000 Hz. A wrist-mounted RGB camera, dedicated camera bracket, cables and other accessories are included.

Requst a quote

Choose your accessories

Five-Finger Robotic Hand with 16 Active Degrees of Freedom

The Dex5-1 is designed for H2 and provides 16 active degrees of freedom across five fingers. Twelve manufacturer-developed micro force-control composite transmission joints and four micro gear-driven joints provide feedback on joint mode, position, velocity and torque without requiring tactile sensors.

The thumb has 4 active degrees of freedom, while each remaining finger has 3, with an additional coupled joint movement. The hand delivers 10 N of fingertip force and ±1 mm fingertip repeatability. It operates on 24–60 V DC and includes a wrist-mounted RGB camera with 1920 × 1080-pixel resolution.

Included in the Package

  • 1 × Dex5-1 five-finger dexterous hand for H2
  • 1 × wrist-mounted RGB camera
  • 1 × dedicated RGB camera bracket
  • Cables and other accessories

Technical Specifications

Mechanics and Movement

  • Designed for: H2
  • Active degrees of freedom: 16
  • Thumb: 4 active DOF
  • Index, middle, ring and little fingers: 3 active DOF each
  • Drive system: 12 micro force-control composite transmission joints and 4 micro gear-driven joints
  • Proprioception: Supported without tactile sensors
  • Thumb joint ranges: −33.5° to 39°; 0° to 100°; 0° to 110°; 0° to 92°
  • Other finger joint ranges: −22° to 22° lateral swing; 0° to 90°; 0° to 95°; 0° to 81° coupled movement
  • Minimum grasping diameter: 10 mm
  • Fingertip repeatability: ±1 mm
  • Fingertip force: 10 N

Electrical and Communication

  • Operating voltage: 24–60 V DC
  • Static current at 58 V: 0.2 A
  • Maximum current at 58 V: 3 A
  • Operating temperature: −20 to +60 °C
  • Communication interface: USB 2.0
  • Communication frequency: 1,000 Hz
  • Joint feedback: Mode, position, velocity and torque

RGB Camera

  • Mounting position: Wrist
  • Resolution: 1920 × 1080 pixels
  • Field of view: 130° diagonal, 120° horizontal and 81° vertical