
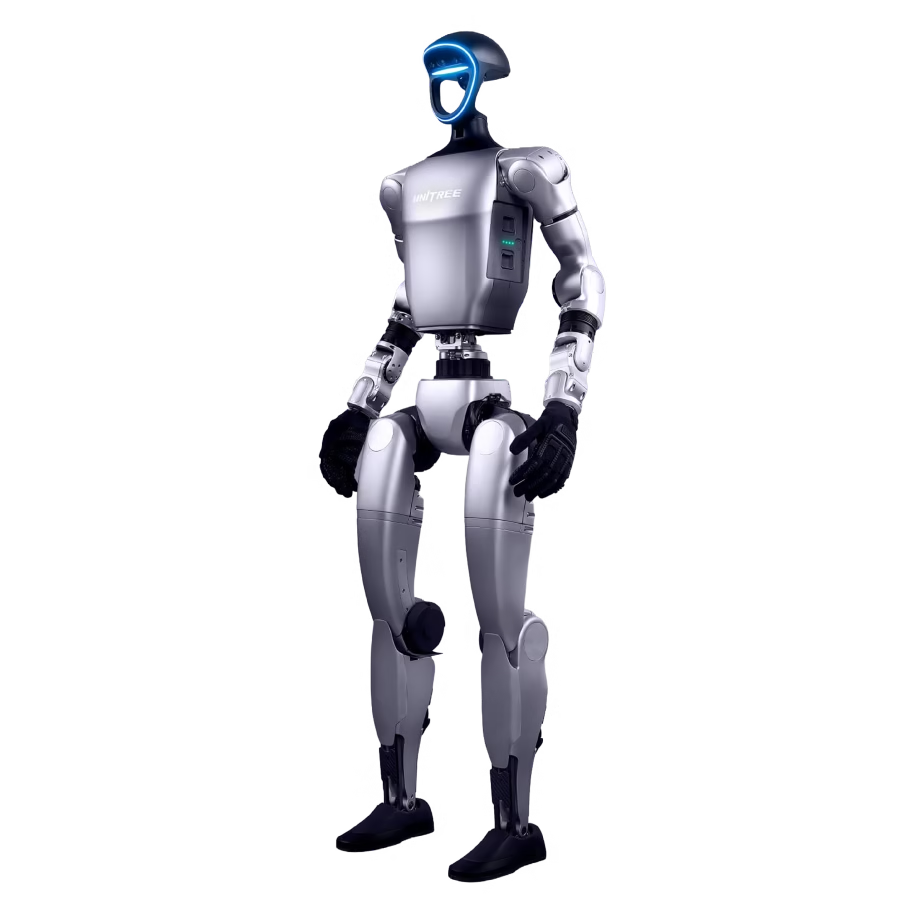
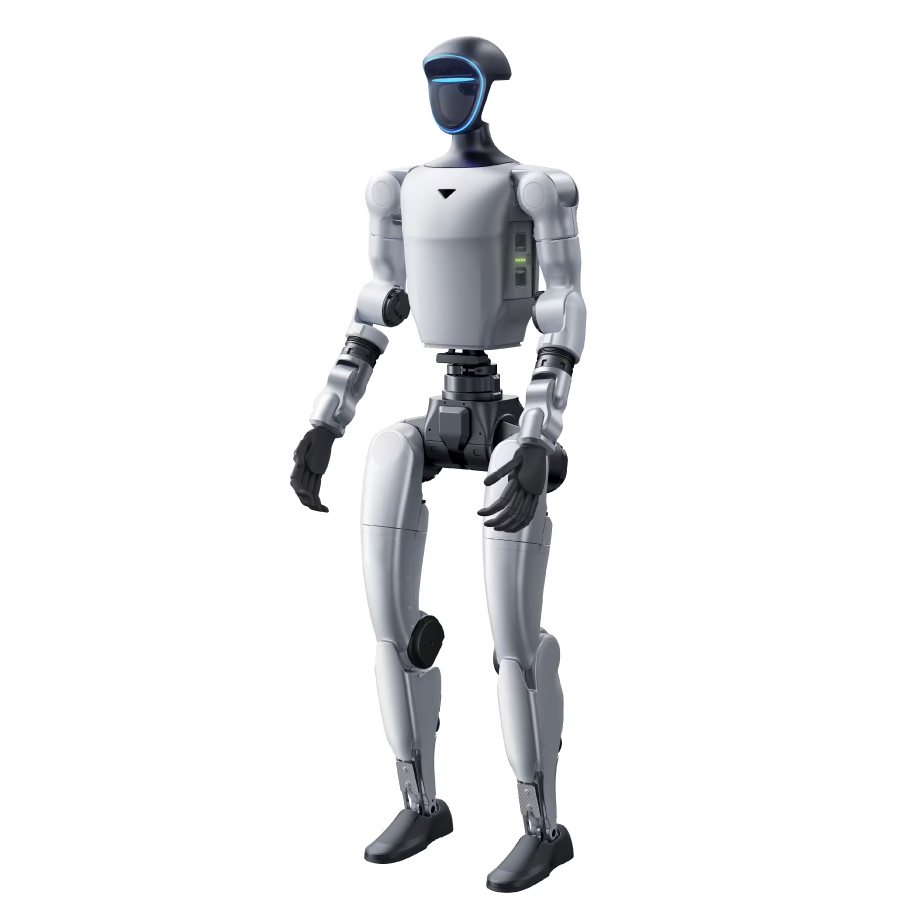
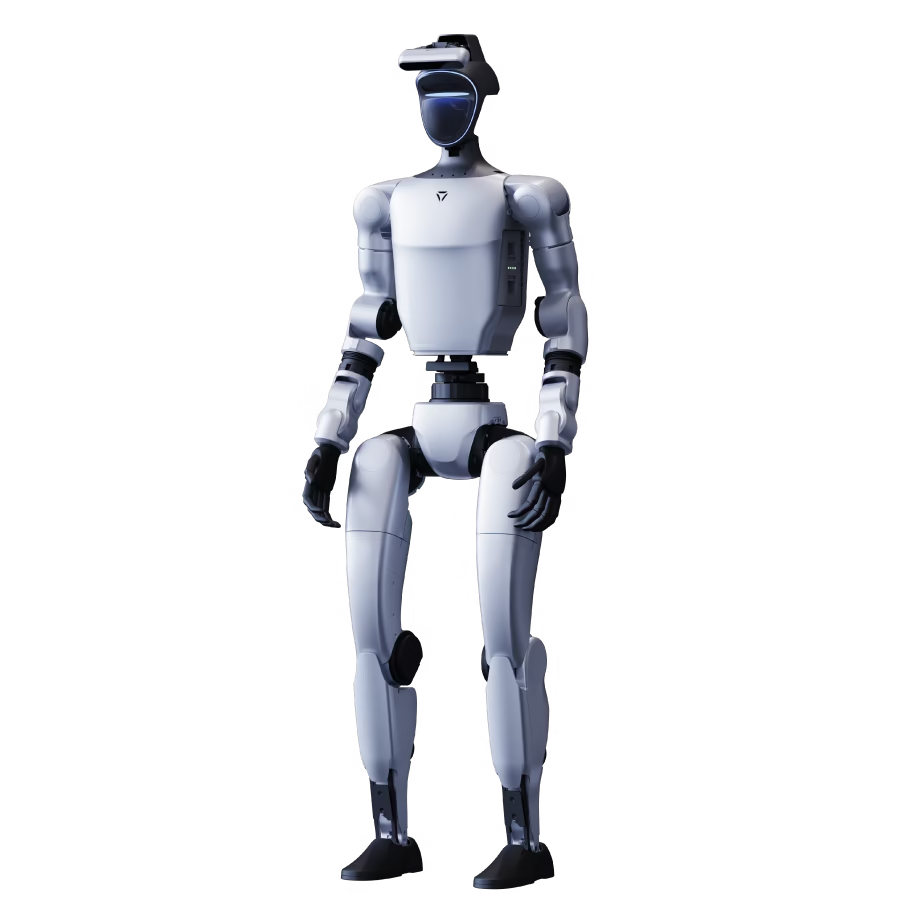
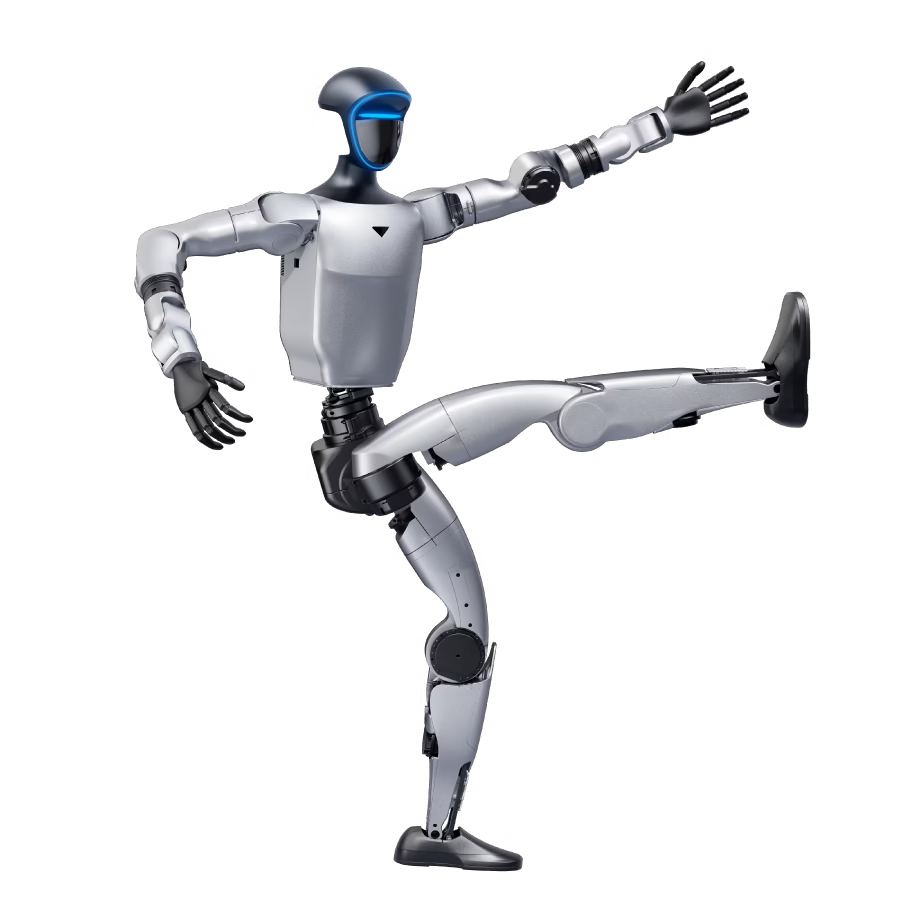
The Unitree G1 is a humanoid robot designed to perform complex tasks with precision. A configurable Unitree humanoid robot for research, education, robotics development, embodied AI and specialised applications.
G1 Basic is the versatile foundation of the Unitree G1 series.
This configuration is supplied by quotation; the final scope, delivery and pricing are confirmed in the quotation.
G1 Pro builds on G1 Basic with reinforced hardware, expanded motion and onboard high-performance computing.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 E combines the upgraded G1 mechanical platform with support for secondary development.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Standard adds a comprehensive development platform to the G1 Basic hardware.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Plus includes the G1 Edu Standard development platform and expands the robot's upper-body mobility.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate A combines the full G1 Edu Plus platform with Dex3-1 force-controlled dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate B adds tactile Dex3-1 dexterous hands to the full G1 Edu Plus platform.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate C combines G1 Edu Plus with Inspire DFQ dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate D combines G1 Edu Plus with tactile Inspire E2 dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate E combines G1 Edu Plus with BrainCo Revo 2 Basic dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate F combines G1 Edu Plus with BrainCo Revo 2 Touch dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate G equips the G1 Edu Plus platform with DEX 2/5 tendon-driven dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate H combines G1 Edu Plus with two Dex1-1 Gripper Plus end effectors.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Ultimate I combines G1 Edu Plus with two highly articulated Wuji Hand2 end effectors.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Professional A combines G1 Edu Standard with Dex3-1 force-controlled dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Professional B combines G1 Edu Standard with tactile Dex3-1 dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Professional E combines G1 Edu Standard with BrainCo Revo 2 Basic dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Professional F combines G1 Edu Standard with two BrainCo Revo 2 Touch dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Professional G equips G1 Edu Standard with DEX 2/5 tendon-driven dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Professional H combines G1 Edu Standard with two Dex1-1 Gripper Plus end effectors.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1 Edu Professional I combines G1 Edu Standard with two Wuji Hand2 end effectors.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-Comp is a competition-oriented G1 configuration with expanded perception, head movement and onboard compute.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
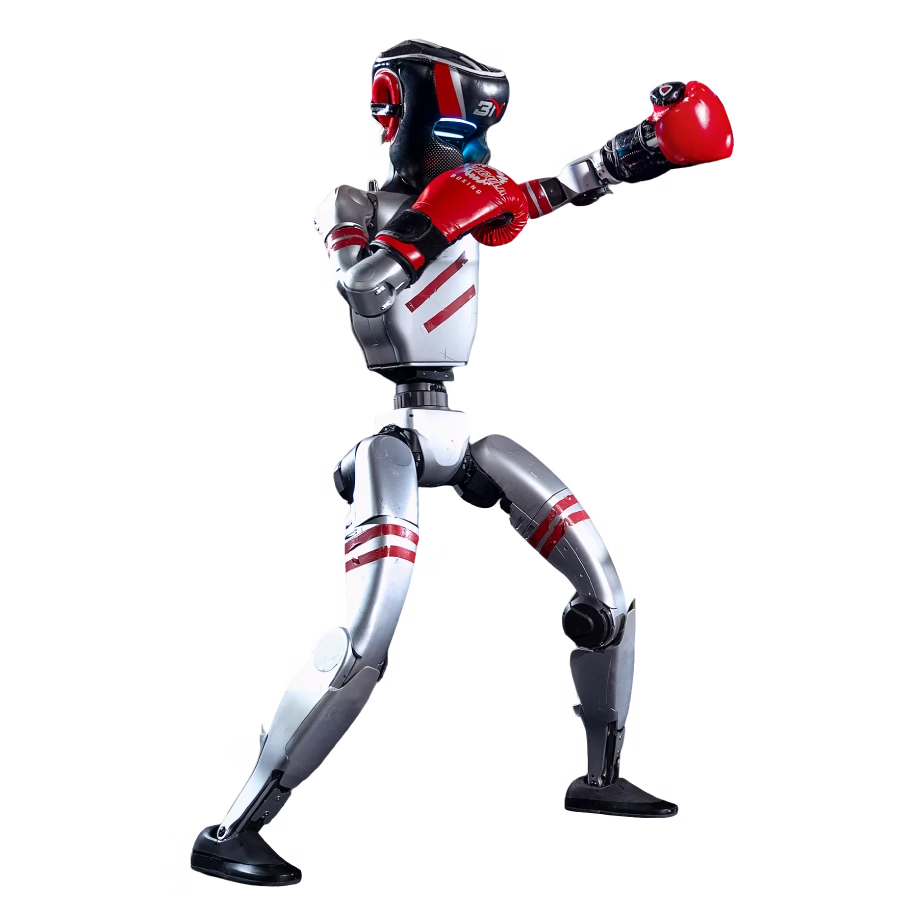
G1 Edu Boxing includes the G1 Edu Plus functions and is reinforced for the documented combat application.
This configuration is supplied by quotation. Maintenance, spare-parts and subsidy conditions must be confirmed in the quotation.
| Specification | G1 Basic | G1 Pro | G1 E | G1 Edu Standard | G1 Edu Plus | G1 Edu Ultimate A | G1 Edu Ultimate B | G1 Edu Ultimate C | G1 Edu Ultimate D | G1 Edu Ultimate E | G1 Edu Ultimate F | G1 Edu Ultimate G | G1 Edu Ultimate H | G1 Edu Ultimate I | G1 Edu Professional A | G1 Edu Professional B | G1 Edu Professional E | G1 Edu Professional F | G1 Edu Professional G | G1 Edu Professional H | G1 Edu Professional I | G1-Comp | G1 Edu Boxing |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| General | |||||||||||||||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series |
| Robot type | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot |
| Main market description | Light industrial, service, residential and academic applications | Tourism, commercial events, media entertainment and content creation | Tourism, commercial events, media entertainment and content creation | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Includes functions of | – | G1 Basic | G1 Basic | G1 Basic | G1 Edu Standard | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | – | G1 Edu Plus |
| Dimensions & Weight | |||||||||||||||||||||||
| Standing dimensions (H × W × D) | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm | 1,320 × 450 × 200 mm |
| Folded dimensions (H × W × D) | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm |
| Robot weight (with battery) | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg |
| Leg length (thigh + shin/calf) | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m | 0.60 m |
| Arm span | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m |
| Degrees of Freedom | |||||||||||||||||||||||
| Total robot/system DoF | 23 | 29 | 29 | 23 | 29 | 43 | 43 | 41 | 41 | 41 | 41 | 33 | 31 | 69 | 37 | 37 | 35 | 35 | 27 | 25 | 63 | 25 | 29 |
| Single leg DoF | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 |
| Waist DoF | 1 | 3 | 3 | 1 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 3 |
| Single arm DoF | 5 | 7 | 7 | 5 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 5 | 5 | 5 | 5 | 5 | 5 | 5 | 5 | 7 |
| Head DoF | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 2 | – |
| Single hand/end-effector DoF | – | – | – | – | – | 7 | 7 | 6 | 6 | 6 | 6 | 2 | 1 | 20 | 7 | 7 | 6 | 6 | 2 | 1 | 20 | – | – |
| Single hand joint count | – | – | – | – | – | – | – | 12 | 12 | 11 | 11 | 10 | – | – | – | – | 11 | 11 | 10 | – | – | – | – |
| Performance & Joint Motion | |||||||||||||||||||||||
| Maximum knee torque | 90 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m |
| Maximum arm payload | 2 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg |
| Waist Z-axis range | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° |
| Waist X-axis range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±45 ° | – |
| Waist Y-axis range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±30 ° | – |
| Knee range | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° |
| Hip pitch (P) range | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° |
| Hip roll (R) range | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° |
| Hip yaw (Y) range | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° |
| Head pitch (P) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | '-90–+22.7 ° | – |
| Head yaw (Y) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | '-50–+50 ° | – |
| Wrist pitch (P) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±92.5 ° | – |
| Wrist yaw (Y) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±92.5 ° | – |
| Hardware & Systems | |||||||||||||||||||||||
| Waist motor | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | IM6010-R32 |
| Wiring | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints |
| Encoders | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint |
| Cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling |
| Power system | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery |
| Battery & Charging | |||||||||||||||||||||||
| Battery capacity | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh | 9,000 mAh |
| Battery life | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours |
| Charger output | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A |
| Compute & Software | |||||||||||||||||||||||
| Base compute | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU |
| High-compute module | – | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | NVIDIA Jetson Orin package | Built-in high-performance expansion computing module |
| Compute performance | – | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS |
| Expansion dock / bay | – | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion bay | Built-in 100 TOPS expansion dock |
| Navigation and positioning software | – | Navigation and positioning software | Navigation and positioning software | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| AI algorithms and technical support | – | – | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | – | – | – | – | – | – | – | AI algorithms included |
| UniStore support | – | Yes | Yes | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Smart OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development | No | No | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Development level | No secondary development | External secondary development is not supported | – | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | – | High-level and low-level secondary development |
| Technical support | – | – | Technical support included | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support included | Technical support, development manuals and ecosystem support |
| Included movements and dances | – | 10+ official movements and dances | 10+ official movements and dances | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Perception, Audio & Connectivity | |||||||||||||||||||||||
| Depth camera | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D455 × 1 | Intel RealSense D435i × 1 |
| LiDAR | 3D LiDAR × 1 | Ultra-wide-angle 3D LiDAR × 1 | Ultra-wide-angle 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 |
| Wrist RGB camera | – | – | – | – | – | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | – | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | – | Wrist RGB camera | Wrist RGB camera | – | – |
| Wrist camera FOV | – | – | – | – | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | – | – |
| Wrist camera resolution | – | – | – | – | – | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | – | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | – | 1920 × 1080 | 1920 × 1080 | – | – |
| Audio input | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | 4-microphone array | Microphone array |
| Audio output | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | 5 W speaker | Built-in stereo speakers |
| Wi-Fi | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | |||||||||||||||||||||||
| Hand / end-effector model | – | – | – | – | – | Dex3-1 force-controlled three-finger dexterous hands | Dex3-1 force-controlled three-finger dexterous hands | Inspire DFQ dexterous hands | Inspire E2 dexterous hands | BrainCo Bionic Dexterous Hand Revo 2 Basic | BrainCo Bionic Dexterous Hand Revo 2 Touch | DEX 2/5 tendon-driven dexterous hands | Dex1-1 Gripper Plus × 2 | Wuji Hand2 five-finger dexterous hands | Dex3-1 force-controlled three-finger dexterous hands | Dex3-1 force-controlled three-finger dexterous hands | BrainCo Bionic Dexterous Hand Revo 2 Basic | BrainCo Bionic Dexterous Hand Revo 2 Touch | DEX 2/5 tendon-driven dexterous hands | Dex1-1 Gripper Plus × 2 | Wuji Hand2 five-finger dexterous hands | – | – |
| Tactile sensing | – | – | – | – | – | No | Yes | No | Yes | No | Yes | No | No | No | No | Yes | No | Yes | No | No | No | – | – |
| Single hand/end-effector weight | – | – | – | – | – | 650 g | 650 g | – | 800 g | 383 g | 383 g | 365 g | 550 g | – | 650 g | 650 g | 383 g | 383 g | 365 g | 550 g | – | – | – |
| Hand/end-effector dimensions (H × W × D) | – | – | – | – | – | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | – | – | 151 × 67 × 70 mm | 143 × 78 × 67 mm | Approximately 185 × 80 × 40 (skeleton) mm | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | 151 × 67 × 70 mm | 143 × 78 × 67 mm | Approximately 185 × 80 × 40 (skeleton) mm | – | – |
| Operating voltage | – | – | – | – | – | 12–58 V | 12–58 V | – | 24 V ±10% | – | – | 24–58 V | – | 16–58 V | 12–58 V | 12–58 V | – | – | 24–58 V | – | 16–58 V | – | – |
| Static current | – | – | – | – | – | 58 V @ 0.2 A | 58 V @ 0.2 A | – | 0.25 A | – | – | – | – | – | 58 V @ 0.2 A | 58 V @ 0.2 A | – | – | – | – | – | – | – |
| Maximum current | – | – | – | – | – | – | – | – | 4 A | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Communication interface / protocol | – | – | – | – | – | USB | USB | – | – | – | – | – | – | Ethernet 1000BASE-T | USB | USB | – | – | – | – | Ethernet 1000BASE-T | – | – |
| Repeatability / control accuracy | – | – | – | – | – | – | – | ±0.20 mm | ±0.20 mm | 0.1° | 0.1° | – | – | – | – | – | 0.1° | 0.1° | – | – | – | – | – |
| Whole-hand / gripping force | – | – | – | – | – | – | – | – | – | 50 N | 50 N | 10 N fingertip force | 5–120 N | ≥15 N fingertip force | – | – | 50 N | 50 N | 10 N fingertip force | 5–120 N | ≥15 N fingertip force | – | – |
| Single-finger pinch force | – | – | – | – | – | – | – | – | – | 15 N | 15 N | – | – | – | – | – | 15 N | 15 N | – | – | – | – | – |
| Thumb gripping force | – | – | – | – | – | – | – | 6 N | 30 N | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Four-finger gripping force | – | – | – | – | – | – | – | 4 N | 28 N | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensors per hand | – | – | – | – | – | – | 33 per hand | – | 17 per hand | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensing capabilities | – | – | – | – | – | – | – | – | – | – | Pressure, friction, direction and proximity | – | – | – | – | – | – | Pressure, friction, direction and proximity | – | – | – | – | – |
| Tactile sensor / force-detection range | – | – | – | – | – | – | – | – | 0–30 N | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensor accuracy | – | – | – | – | – | – | – | – | ≤5% FS | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Hand motion speed | – | – | – | – | – | – | – | Thumb lateral swing 235°/s; thumb flexion 150°/s; four-finger flexion 570°/s | Thumb lateral swing >130°/s; thumb bending >130°/s; four-finger bending >200°/s | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Stroke | – | – | – | – | – | – | – | – | – | – | – | – | 90 mm | – | – | – | – | – | – | 90 mm | – | – | – |
| Gripping load | – | – | – | – | – | – | – | – | – | – | – | – | 20 kg form-fitting; 5 kg friction grip | – | – | – | – | – | – | 20 kg form-fitting; 5 kg friction grip | – | – | – |
| Closing time | – | – | – | – | – | – | – | – | 0.8 s | – | – | – | 0.24 s | – | – | – | – | – | – | 0.24 s | – | – | – |
| Claw length | – | – | – | – | – | – | – | – | – | – | – | – | 80 mm | – | – | – | – | – | – | 80 mm | – | – | – |
| Minimum grasping diameter | – | – | – | – | – | – | – | – | – | – | – | – | – | 0 mm | – | – | – | – | – | – | 0 mm | – | – |
| Control frequency | – | – | – | – | – | – | – | – | – | – | – | – | – | 1000 Hz × 20 axes | – | – | – | – | – | – | 1000 Hz × 20 axes | – | – |
| Control mode | – | – | – | – | – | – | – | – | – | – | – | – | – | MIT hybrid force/position control | – | – | – | – | – | – | MIT hybrid force/position control | – | – |
| Joint backlash | – | – | – | – | – | – | – | – | – | – | – | – | – | <1° | – | – | – | – | – | – | <1° | – | – |
| Hand / end-effector notes | – | – | – | – | – | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Gripping-force resolution 0.50 N; thumb lateral rotation range >65°. | – | Height from middle fingertip to palm base: 160 mm. | Height from middle fingertip to palm base: 160 mm. | No external wiring between the dexterous hands and the robot body. | Fingertip position resolution 0.1 mm; high-speed mode 485. | At least 4 movements per second; force-detection range 0–30 N with 0.005 N sensitivity. The document identifies this edition as without tactile sensing. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Height from middle fingertip to palm base: 160 mm. | Height from middle fingertip to palm base: 160 mm. | No external wiring between the dexterous hands and the robot body. | Fingertip position resolution 0.1 mm; high-speed mode 485. | At least 4 movements per second; force-detection range 0–30 N with 0.005 N sensitivity. The document identifies this edition as without tactile sensing. | – | – |
| Package, Warranty & Notes | |||||||||||||||||||||||
| Included items | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote; 1 combat remote control; 2 boxing gloves; 1 boxing helmet |
| Protective bracket included | No | No | Yes | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | – | No |
| Whole-unit warranty | 8 months | 12 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 0 months |
| Warranty / maintenance terms | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | Default 18-month warranty; extension may be agreed case by case for competition requirements. | No free warranty; robot maintenance and spare-parts replacement are chargeable. |
| Maintenance subsidy | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | RMB 50,000 (USD 7,500); non-cash and restricted to maintenance or spare parts for this product |
| Notes | Protective bracket is not included by default. | Hardware reinforcement and algorithm synergy; protective bracket is not included by default. | The NX expansion module is not included by default and can be purchased separately. | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | Reinforced waist, armour and related hardware. G1 Edu Plus cannot be upgraded to the Combat Edition; the Combat Edition can be used as G1 Edu Plus. |
| Configuration | G1 Basic, G1 Pro, G1 E, G1 Edu Standard, G1 Edu Plus, G1 Edu Ultimate A, G1 Edu Ultimate B, G1 Edu Ultimate C, G1 Edu Ultimate D, G1 Edu Ultimate E, G1 Edu Ultimate F, G1 Edu Ultimate G, G1 Edu Ultimate H, G1 Edu Ultimate I, G1 Edu Professional A, G1 Edu Professional B, G1 Edu Professional E, G1 Edu Professional F, G1 Edu Professional G, G1 Edu Professional H, G1 Edu Professional I, G1 Edu Boxing, G1-Comp |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid robot |
| Application | Research, Education, Development, Service, Entertainment, Competition |
The Unitree G1 Series is a configurable humanoid-robot platform offered in 23 documented configurations, from the foundational G1 Basic to education, professional, dexterous-hand, boxing and competition editions.
Select a configuration and submit the quotation form for a confirmed solution and price.
The Unitree G1 is a humanoid robot designed for tasks that demand high precision and sensitivity. With an impressive range of motion and between 23 and 43 joint motors, depending on configuration, it can perform movements and angles that match—or even surpass—human capability. This makes it ideal for fine-motor tasks such as assembly, sampling, and quality inspection. Its powerful hybrid control system and dexterous hand allow it to manipulate delicate objects reliably and maintain a stable grip, even in varied work environments. In addition, the G1 can be trained through imitation and machine learning, enabling it to adapt quickly to new tasks. To enhance perception, the G1 can be equipped with 3D LiDAR and a depth camera, providing 360-degree situational awareness. This enables robust positioning and safe motion around people and equipment. The platform is modular: in the EDU packages, the waist’s degrees of freedom can be expanded from 1 to 3 and the arm’s from 5 to 7, further improving reach and fine manipulation. In summary, this makes the G1 a flexible and precise platform for research, education, and practical automation tasks where reliable handling and high accuracy are critical.
The Unitree G1 is a humanoid robot designed for tasks that demand high precision and sensitivity. With an impressive range of motion and between 23 and 43 joint motors, depending on configuration, it can perform movements and angles that match—or even surpass—human capability. This makes it ideal for fine-motor tasks such as assembly, sampling, and quality inspection. Its powerful hybrid control system and dexterous hand allow it to manipulate delicate objects reliably and maintain a stable grip, even in varied work environments. In addition, the G1 can be trained through imitation and machine learning, enabling it to adapt quickly to new tasks. To enhance perception, the G1 can be equipped with 3D LiDAR and a depth camera, providing 360-degree situational awareness. This enables robust positioning and safe motion around people and equipment. The platform is modular: in the EDU packages, the waist’s degrees of freedom can be expanded from 1 to 3 and the arm’s from 5 to 7, further improving reach and fine manipulation. In summary, this makes the G1 a flexible and precise platform for research, education, and practical automation tasks where reliable handling and high accuracy are critical.
The Unitree G1 humanoid robot is built to perform tasks with both precision and reliability. Thanks to its advanced technology, the robot’s hands can sense and adjust applied force, allowing it to handle objects gently and accurately. It uses a unique control approach that adapts its movements to the task, enabling human-like precision and accuracy. This makes it ideal for everything from industrial automation to research and development. Combined with the G1’s powerful hybrid position/force control and dexterous hands (such as the Unitree Dex3-1 with tactile sensors), it can not only “match” human performance but also sense and modulate contact forces while gripping, sorting, or assembling. The result is an adaptive, intelligent solution for tasks requiring human interaction and high precision—from lab automation and test environments to educational settings where new skills are trained via human demonstrations.