
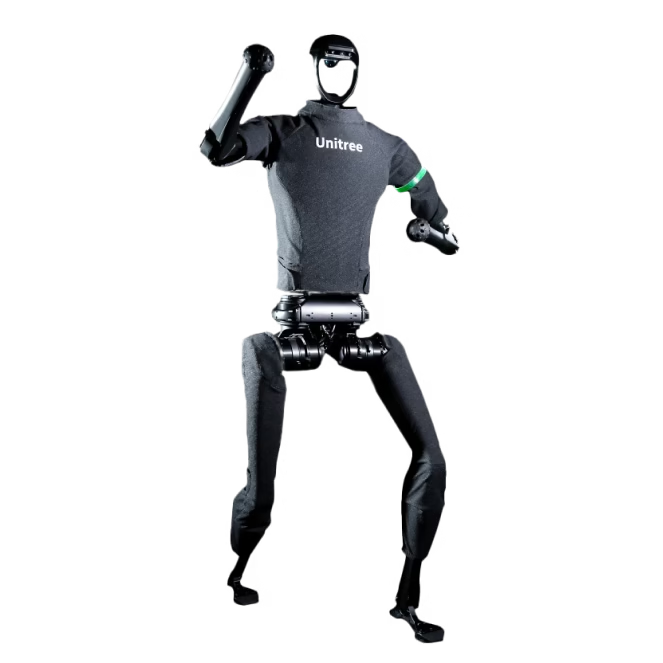
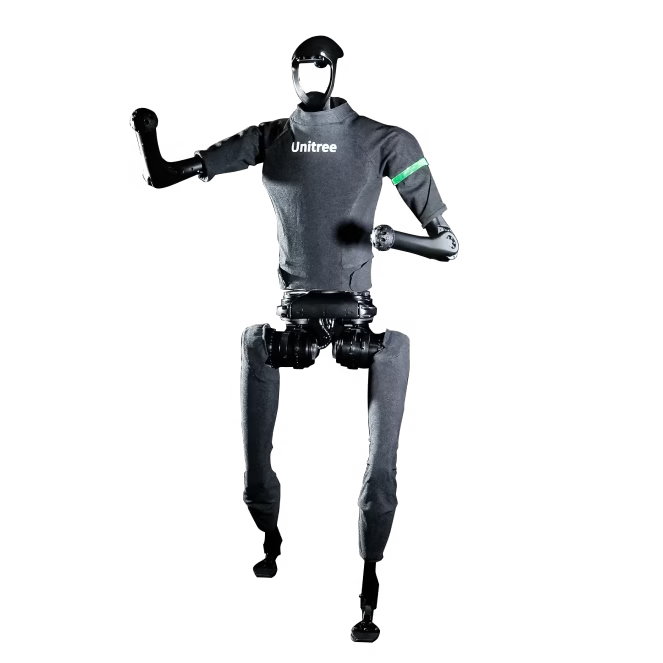
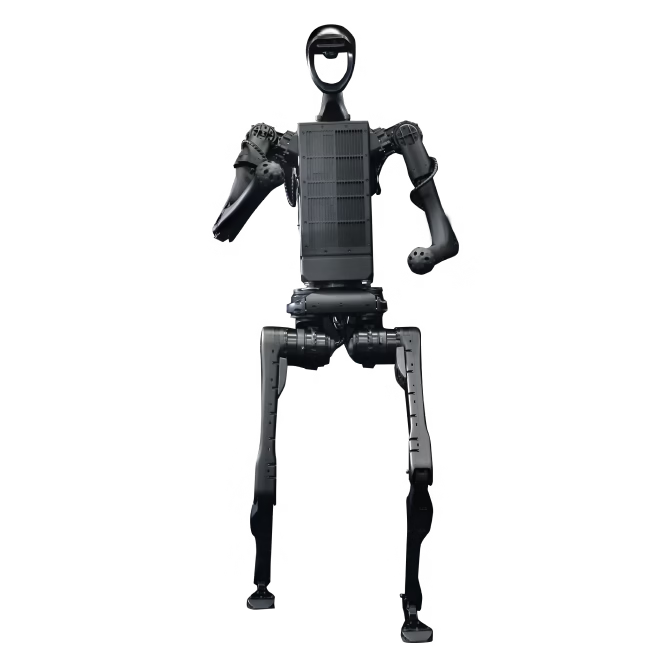
Unitree H1 is a powerful humanoid that combines advanced technology and flexible mobility. With its ability to autonomously navigate complex terrains and perform tasks with high speed and precision, H1 is an ideal solution for a variety of work environments that require both agility and reliability.
| Specification | H1 | H1-2 |
|---|---|---|
| Dimensions & Weight | ||
| Key Dimensions | (1520 + 285) mm × 570 mm × 220 mm | (1503 + 285) mm × 510 mm × 287 mm |
| Thigh and Calf Length | 400 mm × 2 | 400 mm × 2 |
| Total Arm Length | 338 mm × 2 | 685 mm |
| Total Weight | About 47 kg | About 70 kg |
| Degrees of Freedom | ||
| DOF of Each Leg | 5 (Hip × 3 + Knee × 1 + Ankle × 1) | 6 (Hip × 3 + Knee × 1 + Ankle × 2) |
| DOF of Each Arm | 4 (Expandable) | 7 (Shoulder × 3 + Elbow × 1 + Wrist × 3) |
| Joints & Mobility | ||
| Joint Output Bearing | Industrial grade crossed roller bearings (high precision, high load capacity) | Industrial grade crossed roller bearings (high precision, high load capacity) |
| Core Joint Motor | Low inertia high-speed internal rotor PMSM (permanent magnet synchronous motor, better response speed and heat dissipation) | Low inertia high-speed internal rotor PMSM (permanent magnet synchronous motor, better response speed and heat dissipation) |
| Ultimate Torque of Joint Unit | Knee torque: about 360 N·m Hip joint torque: about 220 N·m Ankle torque: about 59 N·m Arm joint torque: about 75 N·m | Knee torque: about 360 N·m Hip joint torque: about 220 N·m Waist joint torque: about 220 N·m Ankle joint torque: about 75 × 2 N·m |
| Mobility | Moving speed of 3.3 m/s (world record); potential mobility > 5 m/s | Moving speed < 2 m/s |
| Battery, Compute & Sensors | ||
| Battery | Battery capacity: 15 Ah (0.864 kWh) Maximum voltage: 67.2 V | Battery capacity: 15 Ah (0.864 kWh) Maximum voltage: 67.2 V |
| Control and Perception Computing Power | Standard configuration: Intel Core i5 (Platform Function) and Intel Core i7 (User Development) Optional configuration: Intel Core i7 or NVIDIA Jetson Orin NX | Standard configuration: Intel Core i5 (Platform Function) and Intel Core i7 (User Development) Optional configuration: Intel Core i7 or NVIDIA Jetson Orin NX (up to three) |
| Sensor Configuration | 3D LiDAR + Depth Camera | 3D LiDAR + Depth Camera |
| Hands & Payload | ||
| Dexterous Hand | Optional | Optional Dex5-1 or other ambidextrous hands |
| Arm Joint Performance (Peak Torque) | — | Shoulder: about 120 N·m Elbow: about 120 N·m Wrist: about 30 N·m |
| Arm Normal Load | — | Peak: about 21 kg Rated: about 7 kg |
Note: The product continues to be iterated and optimized. Please refer to the delivered product for the final specification.
The appearance of the shipping version may differ from the official website version. If appearance details are important, please consult the sales team before purchasing.
Parameters may differ between products. Please select a configuration according to your requirements.
The global humanoid robot industry is currently in an early stage of development. Individual users are strongly advised to understand the limitations of humanoid robots thoroughly before purchasing.
This product is a civilian robot. Users must not make dangerous modifications or use the robot in a hazardous manner.
| Configuration | H1, H1-2 |
|---|
Unitree H1 is a humanoid robot with exceptional performance and flexibility. Equipped with an advanced drive system, it can run at speeds of up to 3.3 m/s and perform tasks with a high degree of stability and agility. This makes it the perfect solution for both industrial and complex working environments.
The groundbreaking Unitree H1 humanoid robot has the ability to walk and run autonomously in complex environments. Whether on uneven ground or in confined spaces, the H1 offers stable walking and high freedom of movement, making it a reliable aid for both indoor and outdoor use.
Unitree H1’s advanced 3D LiDAR technology and depth camera give the robot superior ability to analyse its surroundings. With real-time spatial data, H1 can navigate and interact with its environment safely and efficiently, making it ideal for tasks that require high precision and adaptation.