
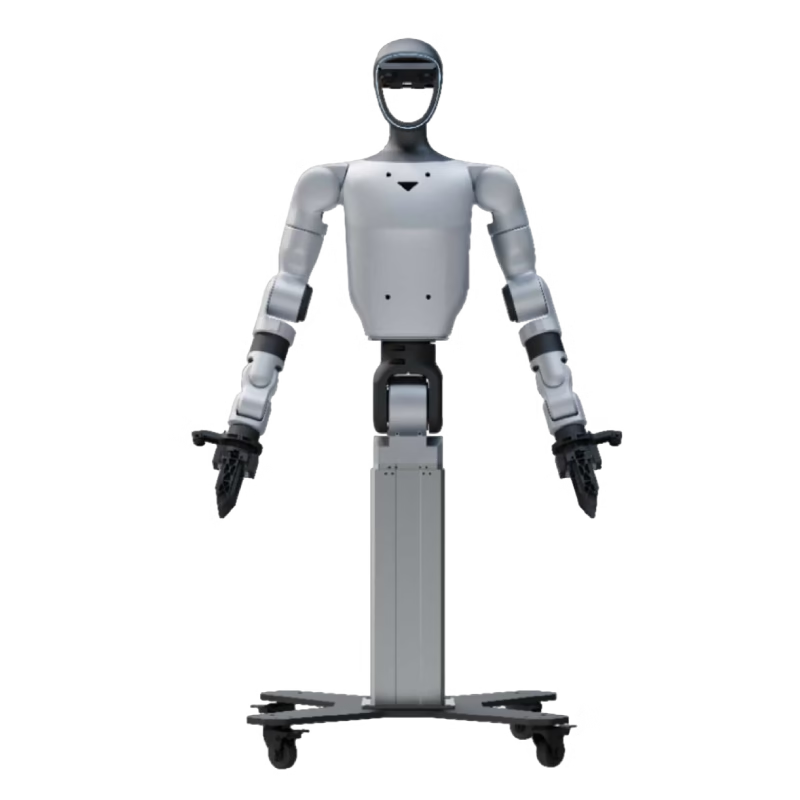
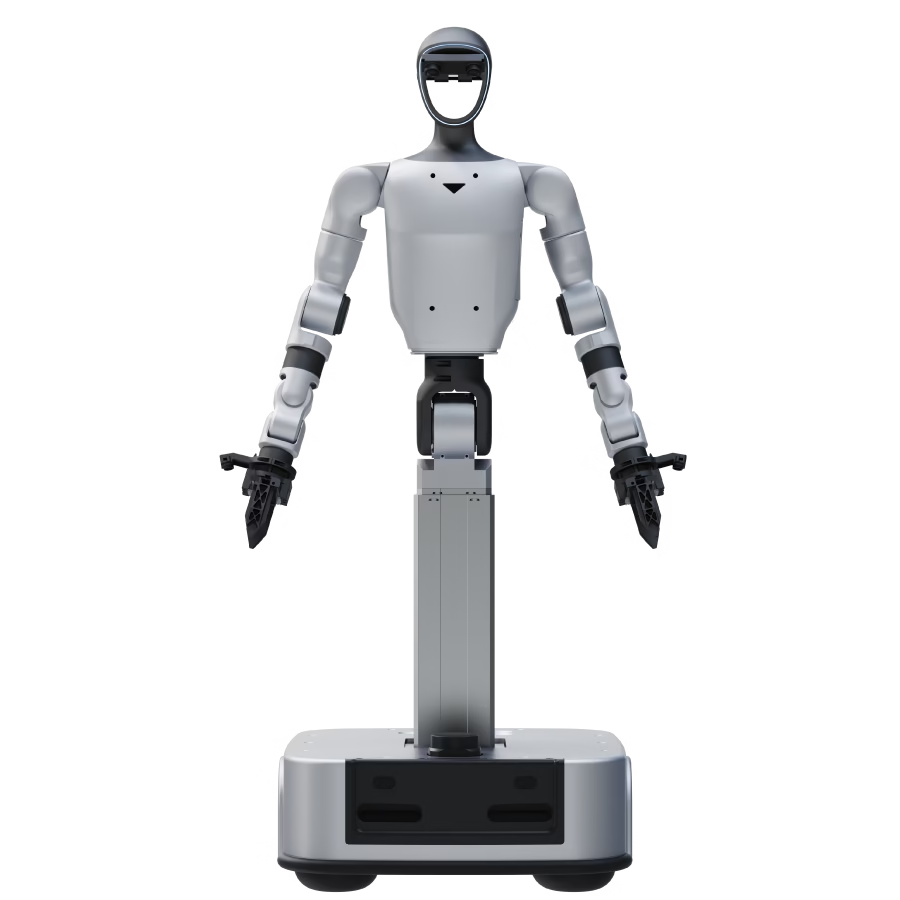
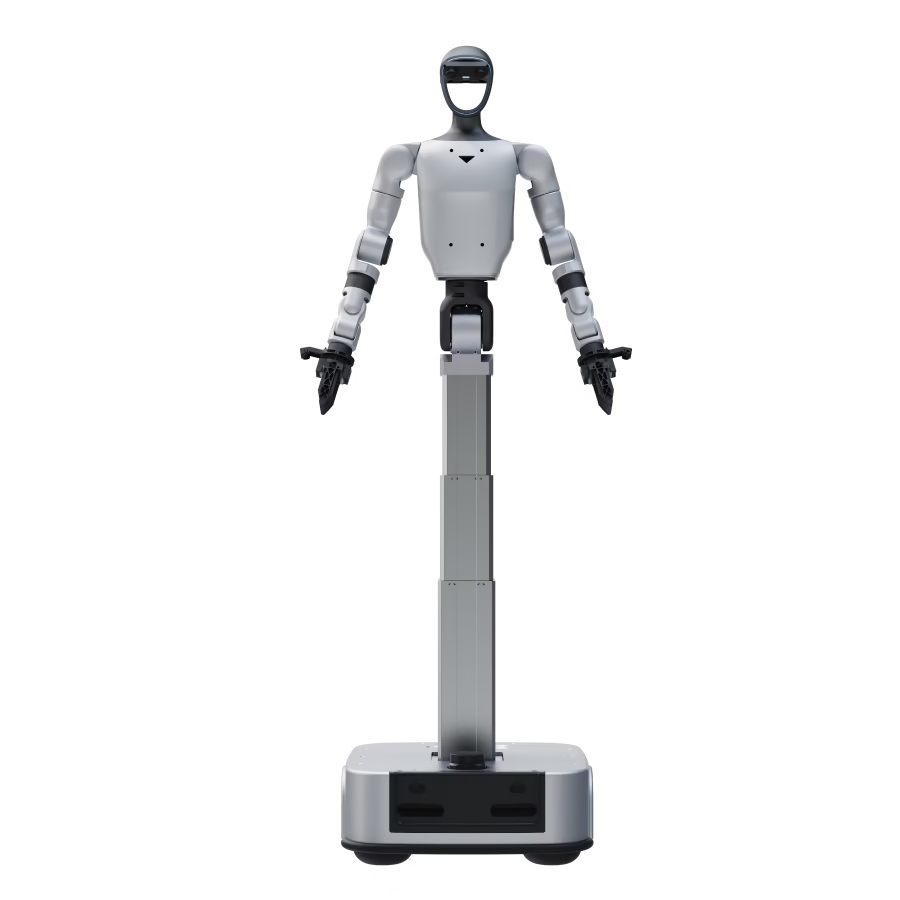
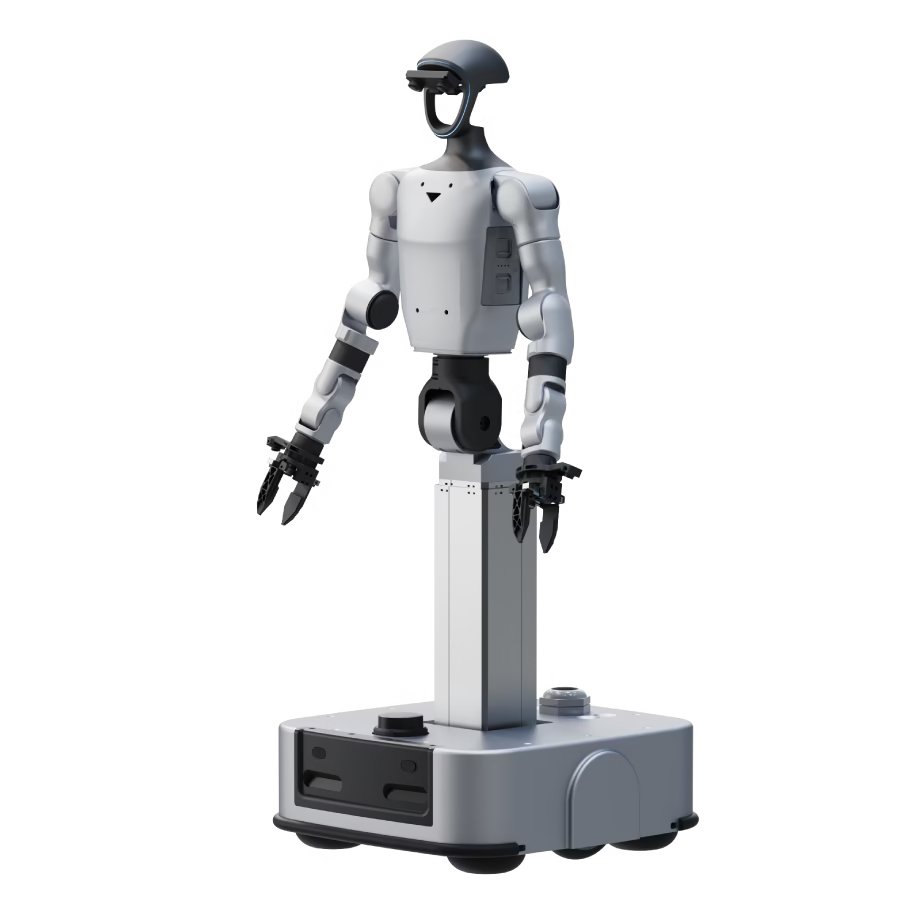
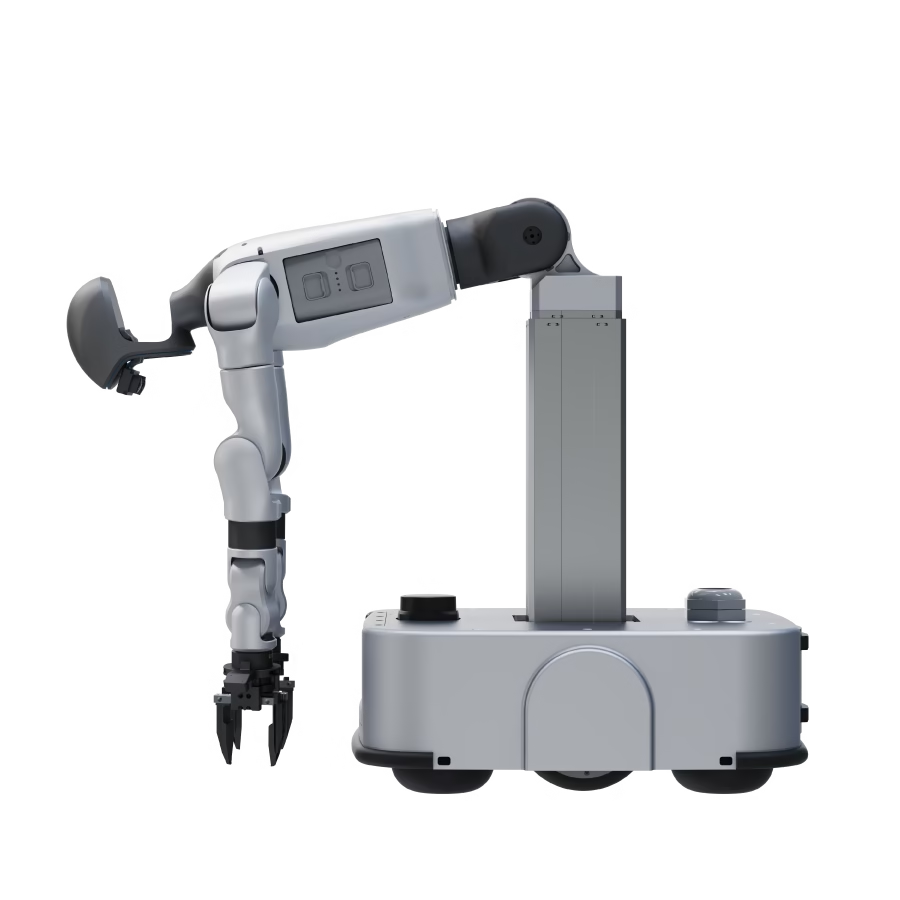
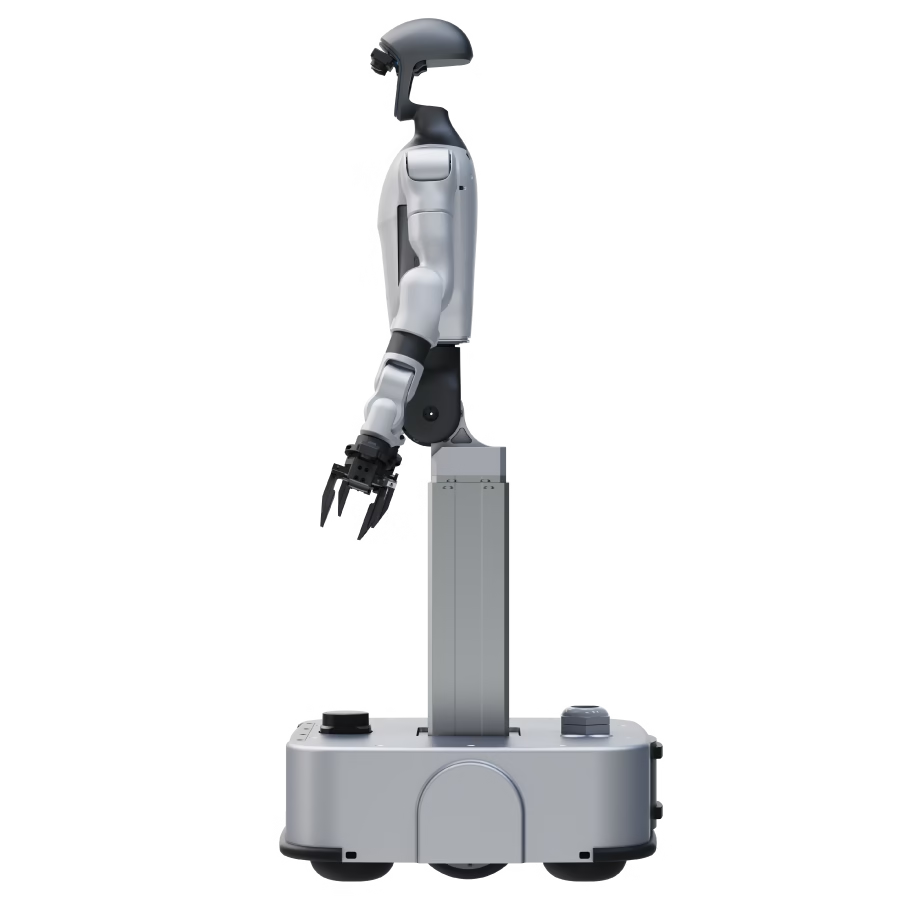
A configurable Unitree G1-D mobile manipulation and data-collection platform with Standard and wheeled Ultimate configurations.
G1-D Standard A combines the G1-D upper-body platform with two Dex1-1 Plus grippers for mobile manipulation and data-collection tasks.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Standard B adds non-tactile Dex3-1 force-controlled three-finger dexterous hands to the Standard A platform.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Standard C adds tactile Dex3-1 force-controlled three-finger dexterous hands with 33 tactile sensors per hand.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Standard D equips the Standard A platform with two BrainCo Revo 2 Basic five-finger dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Standard E equips the Standard A platform with two tactile BrainCo Revo 2 five-finger dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Ultimate A adds a powered wheeled base, expanded perception and two advanced Dex1-1 force-controlled grippers.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Ultimate B adds non-tactile Dex3-1 force-controlled three-finger dexterous hands to the Ultimate A platform.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Ultimate C adds tactile Dex3-1 force-controlled three-finger dexterous hands with 33 tactile sensors per hand.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Ultimate D equips the Ultimate A platform with two BrainCo Revo 2 Basic five-finger dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
G1-D Ultimate E equips the Ultimate A platform with two tactile BrainCo Revo 2 five-finger dexterous hands.
Final compatibility, configuration, delivery and pricing are confirmed in the quotation.
| Specification | G1-D Standard A | G1-D Standard B | G1-D Standard C | G1-D Standard D | G1-D Standard E | G1-D Ultimate A | G1-D Ultimate B | G1-D Ultimate C | G1-D Ultimate D | G1-D Ultimate E |
|---|---|---|---|---|---|---|---|---|---|---|
| General | ||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series |
| Robot type | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform |
| Functional description | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. |
| Includes functions of | – | G1-D Standard A | G1-D Standard A | G1-D Standard A | G1-D Standard A | – | G1-D Ultimate A | G1-D Ultimate A | G1-D Ultimate A | G1-D Ultimate A |
| Dimensions & Structure | ||||||||||
| Minimum dimensions (H × W × D) | 1,260 × 500 × 500 mm | 1,260 × 500 × 500 mm | 1,260 × 500 × 500 mm | 1,260 × 500 × 500 mm | 1,260 × 500 × 500 mm | 1,260 × 525 × 570 mm | 1,260 × 525 × 570 mm | 1,260 × 525 × 570 mm | 1,260 × 525 × 570 mm | 1,260 × 525 × 570 mm |
| Maximum dimensions (H × W × D) | 1,680 × 500 × 500 mm | 1,680 × 500 × 500 mm | 1,680 × 500 × 500 mm | 1,680 × 500 × 500 mm | 1,680 × 500 × 500 mm | 1,680 × 525 × 570 mm | 1,680 × 525 × 570 mm | 1,680 × 525 × 570 mm | 1,680 × 525 × 570 mm | 1,680 × 525 × 570 mm |
| Robot weight with battery | 50 kg | 50 kg | 50 kg | 50 kg | 50 kg | 80 kg | 80 kg | 80 kg | 80 kg | 80 kg |
| Maximum operating height | 2,000 mm | 2,000 mm | 2,000 mm | 2,000 mm | 2,000 mm | 2,000 mm | 2,000 mm | 2,000 mm | 2,000 mm | 2,000 mm |
| Degrees of Freedom | ||||||||||
| Total system DoF | 19 | 31 | 31 | 29 | 29 | 21 | 33 | 33 | 31 | 31 |
| Robot DoF excluding end effectors | 17 | 17 | 17 | 17 | 17 | 19 | 19 | 19 | 19 | 19 |
| Single arm DoF | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Waist DoF | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Vertical column DoF | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Mobile base DoF | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 |
| Single hand/end-effector DoF | 1 | 7 | 7 | 6 | 6 | 1 | 7 | 7 | 6 | 6 |
| Single hand joint count | – | – | – | 11 | 11 | – | – | – | 11 | 11 |
| Motion & Performance | ||||||||||
| Arm payload | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg |
| Arm reach | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m | 0.45 m |
| Waist Z-axis range | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° |
| Waist Y-axis range | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° | '-2.5° to +135° |
| Lift stroke | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 450 mm | 450 mm | 450 mm | 450 mm | 450 mm |
| Lift accuracy | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm |
| Maximum lift speed | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s |
| Cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling |
| Mobile Base | ||||||||||
| Base dimensions (L × W × H) | – | – | – | – | – | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm |
| Drive system | – | – | – | – | – | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive |
| Maximum base speed | – | – | – | – | – | 1.50 m/s | 1.50 m/s | 1.50 m/s | 1.50 m/s | 1.50 m/s |
| In-place 360° rotation | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| LiDAR units | – | – | – | – | – | 1 | 1 | 1 | 1 | 1 |
| Base depth cameras | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 |
| Physical collision sensor | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| Low-lying obstacle recognition sensor | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| Battery & Power | ||||||||||
| Power modes | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile |
| Battery type | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Built-in base battery | Built-in base battery | Built-in base battery | Built-in base battery | Built-in base battery |
| Battery capacity | 9 Ah | 9 Ah | 9 Ah | 9 Ah | 9 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah |
| Battery life | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 6 hours | 6 hours | 6 hours | 6 hours | 6 hours |
| Charger output voltage | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V |
| Charger output current | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A |
| Charging pile output voltage | – | – | – | – | – | 51 V | 51 V | 51 V | 51 V | 51 V |
| Charging pile output current | – | – | – | – | – | 10 A | 10 A | 10 A | 10 A | 10 A |
| Power / charging notes | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile |
| Compute, Control & Software | ||||||||||
| CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU |
| Compute module | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB |
| AI compute performance | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS |
| Optional high-compute modules | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) |
| Control | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included |
| OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development support | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Visualization PC included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Perception, Audio & Connectivity | ||||||||||
| Perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors |
| Head camera | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 |
| Head camera FOV | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° |
| Head camera resolution | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 |
| Wrist cameras | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 |
| Wrist camera FOV | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° |
| Wrist camera resolution | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 |
| Audio input | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array |
| Audio output | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker |
| Wi-Fi | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | ||||||||||
| Hand / end-effector model | Dex1-1 Plus grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | BrainCo Bionic Dexterous Hand Revo 2 Basic × 2 | BrainCo Bionic Dexterous Hand Revo 2 Tactile × 2 | Dex1-1 force-controlled grippers, Advanced Version × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | BrainCo Bionic Dexterous Hand Revo 2 Basic × 2 | BrainCo Bionic Dexterous Hand Revo 2 Tactile × 2 |
| Tactile sensing | No | No | Yes | No | Yes | – | No | Yes | No | Yes |
| Single hand/end-effector weight | 550 g | 650 g | 650 g | 383 g | 383 g | – | 650 g | 650 g | 383 g | 383 g |
| Hand/end-effector dimensions | 143 × 78 × 67 mm | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | – | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – |
| Hand height | – | – | – | 160 mm | 160 mm | – | – | – | 160 mm | 160 mm |
| Single hand/end-effector DoF | 1 | 7 | 7 | 6 | 6 | 1 | 7 | 7 | 6 | 6 |
| Single hand joint count | – | – | – | 11 | 11 | – | – | – | 11 | 11 |
| Operating voltage | – | 12–58 V | 12–58 V | – | – | – | 12–58 V | 12–58 V | – | – |
| Static current | – | 0.2 A at 58 V | 0.2 A at 58 V | – | – | – | 0.2 A at 58 V | 0.2 A at 58 V | – | – |
| Communication interface / protocol | High-speed 485 | USB | USB | – | – | – | USB | USB | – | – |
| Repeatability / control accuracy | – | – | – | 0.1° | 0.1° | – | – | – | 0.1° | 0.1° |
| Whole-hand / gripping force | – | – | – | 50 N | 50 N | – | – | – | 50 N | 50 N |
| Single-finger pinch force | – | – | – | 15 N | 15 N | – | – | – | 15 N | 15 N |
| Adjustable force range | 5–120 N adjustable | – | – | – | – | – | – | – | – | – |
| Position resolution | 0.1 mm | – | – | – | – | – | – | – | – | – |
| Gripper stroke | 90 mm | – | – | – | – | – | – | – | – | – |
| Closing time | 0.24 s for full stroke | – | – | – | – | – | – | – | – | – |
| Claw length | 80 mm | – | – | – | – | – | – | – | – | – |
| Form-closure gripping payload | 20 kg | – | – | – | – | – | – | – | – | – |
| Friction gripping payload | 5 kg | – | – | – | – | – | – | – | – | – |
| Tactile sensors per hand | – | – | 33 | – | – | – | – | 33 | – | – |
| Tactile perception range | – | – | 10–2500 g | – | – | – | – | 10–2500 g | – | – |
| Tactile sensing capabilities | – | – | – | – | Pressure, friction, direction and proximity sensing | – | – | – | – | Pressure, friction, direction and proximity sensing |
| Hand/wrist RGB camera included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Hand / end-effector notes | Two-finger grippers; specifications are per gripper unless otherwise stated. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | The supplied document does not state detailed specifications for the Advanced Version gripper. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. |
| Package, Warranty & Notes | ||||||||||
| Included items | Dex1-1 Plus grippers × 2; handheld remote controller; visualization PC | Dex3-1 non-tactile dexterous hands × 2; handheld remote controller; visualization PC | Dex3-1 tactile dexterous hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Basic hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Tactile hands × 2; handheld remote controller; visualization PC | Dex1-1 Advanced grippers × 2; handheld remote controller; visualization PC | Dex3-1 non-tactile dexterous hands × 2; handheld remote controller; visualization PC | Dex3-1 tactile dexterous hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Basic hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Tactile hands × 2; handheld remote controller; visualization PC |
| Whole-unit warranty | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months |
| Configuration | G1-D Standard A, G1-D Standard B, G1-D Standard C, G1-D Standard D, G1-D Standard E, G1-D Ultimate A, G1-D Ultimate B, G1-D Ultimate C, G1-D Ultimate D, G1-D Ultimate E |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid mobile manipulator |
| Application | Research, Education, Development, Data collection, Teleoperation |
The Unitree G1-D Series is a configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection.
The mobile base allows G1-D to navigate between workstations, objects, and surfaces where tasks are performed. With sensor and camera input, it moves in a controlled way and avoids collisions.
G1-D is built for research and development workflows where scenarios must be set up and executed quickly. It is easy to control, adjust, and use as a flexible platform for different tasks.
With two articulated arms and a gripping function, G1-D can pick up, move, and handle objects, supporting projects where object manipulation is essential.