
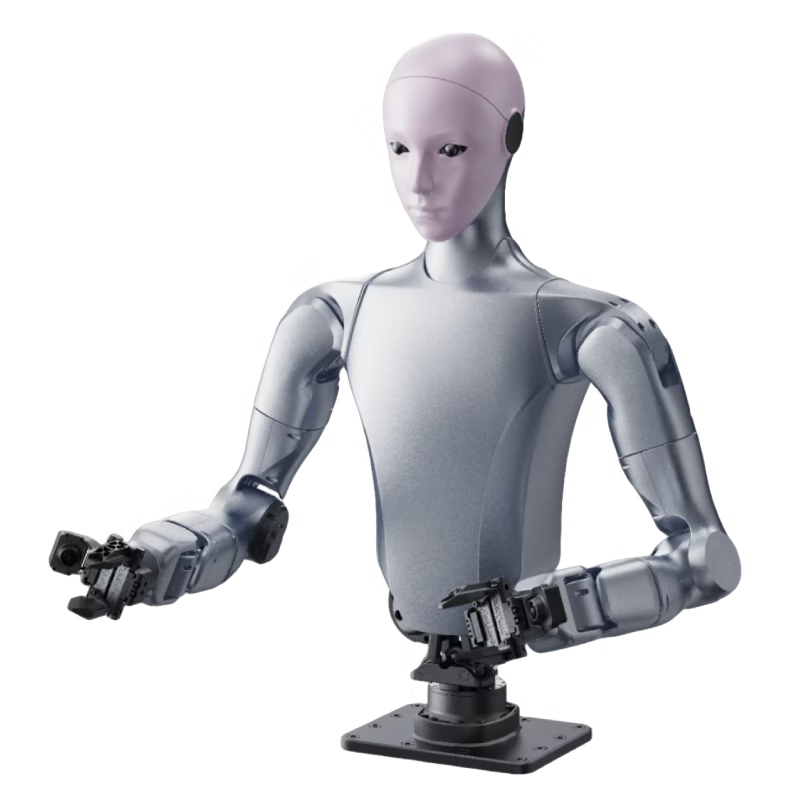
A compact upper-body Unitree H2 platform for research, embodied AI and advanced manipulation.
H2-A Standard A combines the compact upper-body H2-A platform with Dex1-1 Gripper Plus × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard B combines the compact upper-body H2-A platform with Dex3-1 force-controlled three-finger dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard C combines the compact upper-body H2-A platform with Dex3-1 force-controlled three-finger dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard D combines the compact upper-body H2-A platform with Dex5-1 five-finger dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard E combines the compact upper-body H2-A platform with Dex5-1P five-finger dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard F combines the compact upper-body H2-A platform with BrainCo Revo 2 Basic dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard G combines the compact upper-body H2-A platform with BrainCo Revo 2 Touch dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard H combines the compact upper-body H2-A platform with Inspire DFQ dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard I combines the compact upper-body H2-A platform with Inspire E2 dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard J combines the compact upper-body H2-A platform with BrainCo Revo 3 U21 dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard K combines the compact upper-body H2-A platform with BrainCo Revo 3 U21T dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard L combines the compact upper-body H2-A platform with BrainCo Revo 3 U21VT visual-tactile dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
H2-A Standard M combines the compact upper-body H2-A platform with Wuji Hand 2 five-finger dexterous hands × 2.
Final compatibility, delivery and pricing are confirmed in the quotation.
| Specification | H2-A Standard A | H2-A Standard B | H2-A Standard C | H2-A Standard D | H2-A Standard E | H2-A Standard F | H2-A Standard G | H2-A Standard H | H2-A Standard I | H2-A Standard J | H2-A Standard K | H2-A Standard L | H2-A Standard M |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| General | |||||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series | H2-A Series |
| Robot type | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform |
| Functional description | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. | Configurable humanoid upper-body platform for manipulation, teleoperation, secondary development and data collection. |
| Includes functions of | – | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A | H2-A Standard A |
| Dimensions & Structure | |||||||||||||
| Overall height | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm | 780 mm |
| Overall width | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm | 444 mm |
| Overall depth | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm | 200 mm |
| Weight including upper-body battery | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg | 34.40 kg |
| Degrees of Freedom | |||||||||||||
| Total system DoF | 21 | 33 | 33 | 51 | 51 | 31 | 31 | 31 | 31 | 61 | 61 | 61 | 59 |
| Robot DoF excluding end effectors | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 |
| Single arm DoF | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Waist DoF | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 |
| Head DoF | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Single hand/end-effector DoF | 1 | 7 | 7 | 16 | 16 | 6 | 6 | 6 | 6 | 21 | 21 | 21 | 20 |
| Single hand joint count | – | – | – | 16 | 16 | 11 | 11 | 12 | 12 | – | – | – | – |
| Performance | |||||||||||||
| Peak arm payload | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg |
| Rated arm payload | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg |
| Single arm reach | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm | 600 mm |
| Battery & Power | |||||||||||||
| Power supply methods | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply | H2-A upper-body battery and charger, or external power supply |
| Battery type | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery | H2-A upper-body battery |
| Battery endurance | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours | 8 hours |
| Continuous external power supported | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Power notes | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. | Supports continuous external power for 7 × 24-hour operation. |
| Compute, Control & Software | |||||||||||||
| PC1 / platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer |
| PC2 / user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer |
| PC3 / optional high-compute module | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 |
| PC4 / optional module | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 |
| Optional computing performance | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS |
| Control | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included |
| Smart OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development support | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Perception & Connectivity | |||||||||||||
| Perception sensors | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras |
| Head camera | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 |
| Wrist cameras | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 |
| Wrist camera FOV | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° |
| Wrist camera resolution | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 |
| Wi-Fi | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | |||||||||||||
| Hand / end-effector model | Dex1-1 Plus grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | Dex5-1 force-controlled dexterous hands, non-tactile × 2 | Dex5-1P force-controlled dexterous hands, tactile × 2 | BrainCo Revo2 Basic bionic dexterous hands × 2 | BrainCo Revo2 Touch tactile bionic dexterous hands × 2 | Inspire DFQ dexterous hands, non-tactile × 2 | Inspire E2 dexterous hands, tactile × 2 | BrainCo Revo3 U21 dexterous hands, non-tactile × 2 | BrainCo Revo3 U21T tactile dexterous hands × 2 | BrainCo Revo3 U21VT visual-tactile dexterous hands × 2 | Wuji Hand 2 dexterous hands, non-tactile × 2 |
| Tactile sensing | No | No | Yes | No | Yes | No | Yes | No | Yes | No | Yes | Yes | No |
| Single hand/end-effector weight | 550 g | 650 g | 650 g | – | – | 383 g | 383 g | – | 800 g | – | – | – | – |
| Hand/end-effector dimensions | 143 × 78 × 67 | 175 × 88 × 77 | 175 × 88 × 77 | – | – | – | – | – | – | 215 × 105 × 50 | 215 × 105 × 50 | 215 × 105 × 50 | Approximately 185 × 80 × 40 |
| Hand height | – | – | – | – | – | 160 mm | 160 mm | – | – | – | – | – | – |
| Operating voltage | – | 12–58 V | 12–58 V | 24–60 V DC | 24–60 V DC | – | – | – | 24 V ±10% | 12–80 V | 12–80 V | 12–80 V | 16–58 V DC |
| Static current | – | 0.2 A at 58 V | 0.2 A at 58 V | 0.2 A at 58 V | 0.2 A at 58 V | – | – | – | 0.25 A | – | – | – | – |
| Maximum current | – | – | – | 3 A at 58 V | 3 A at 58 V | – | – | – | 4 A | 10 A at 24 V | 10 A at 24 V | 10 A at 24 V | – |
| Communication interface / protocol | High-speed RS-485 | USB | USB | USB 2.0 at 1000 Hz | USB 2.0 at 1000 Hz | – | – | – | – | – | – | – | 1000BASE-T Ethernet |
| Repeatability / positioning accuracy | 0.1 mm fingertip-position resolution | – | – | ±1 mm | ±1 mm | 0.1° | 0.1° | ±0.20 mm | ±0.20 mm | 0.1° | 0.1° | 0.1° | – |
| Whole-hand / palm grip force | 5–120 N adjustable | – | – | – | – | 50 N | 50 N | – | – | 70 N palm/whole-hand grip | 70 N palm/whole-hand grip | 70 N palm/whole-hand grip | – |
| Fingertip / pinch force | – | – | – | 10 N fingertip force | 10 N fingertip force | 15 N | 15 N | – | – | 20 N fingertip pinch | 20 N fingertip pinch | 20 N fingertip pinch | Peak fingertip force ≥15 N |
| Thumb gripping force | – | – | – | – | – | – | – | 6 N | 30 N | – | – | – | – |
| Four-finger gripping force | – | – | – | – | – | – | – | 4 N | 28 N | – | – | – | – |
| Grip-force resolution | – | – | – | – | – | – | – | 0.50 N | – | – | – | – | – |
| Whole-hand payload | – | – | – | – | – | – | – | – | – | 20 kg | 20 kg | 20 kg | – |
| Four-finger payload | – | – | – | – | – | – | – | – | – | 5 kg | 5 kg | 5 kg | – |
| Form-closure gripping payload | 20 kg | – | – | – | – | – | – | – | – | – | – | – | – |
| Friction gripping payload | 5 kg | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensors per hand | – | – | 33 | – | – | – | – | – | 17 | – | – | – | – |
| Array sensors per hand | – | – | – | – | 12 | – | – | – | – | – | – | – | – |
| Pressure sensors per hand | – | – | – | – | 94 | – | – | – | – | – | – | – | – |
| Tactile sensing capabilities | – | – | – | – | – | – | Pressure, friction, direction and proximity sensing | – | – | – | Full-palm tactile sensing | Full-palm visual-tactile sensing | – |
| Tactile / force-detection range | – | – | – | – | 10–2500 g; non-destructive tolerance up to 20 kg | – | – | – | 0–30 N | – | 0–25 N | 0–25 N | – |
| Tactile accuracy / sensitivity | – | – | – | – | – | – | – | – | ≤5% FS | – | 0.01 N resolution | 0.01 N resolution | – |
| Minimum measurable visual-tactile deformation | – | – | – | – | – | – | – | – | – | – | – | 130 | – |
| Hand / finger motion speed | – | – | – | – | – | – | – | Thumb lateral >235°/s; thumb flexion >150°/s; four fingers >570°/s | Thumb lateral/flexion >130°/s; four fingers >200°/s | Opening/closing up to 3 Hz | Opening/closing up to 3 Hz | Opening/closing up to 3 Hz | Opening/closing ≥4 times/s |
| Gripper stroke | 90 mm | – | – | – | – | – | – | – | – | – | – | – | – |
| Closing time | 0.24 s for full stroke | – | – | – | – | – | – | – | 0.8 s | – | – | – | – |
| Finger / claw length | 80 mm | – | – | – | – | – | – | – | – | – | – | – | – |
| Minimum grasping diameter | – | – | – | 10 | 10 | – | – | – | – | 10 | 10 | 10 | 0 |
| Maximum grasping diameter | – | – | – | – | – | – | – | – | – | 150 | 150 | 150 | – |
| Control frequency | – | – | – | – | – | – | – | – | – | 500 Hz | 500 Hz | 500 Hz | 1000 Hz × 20 axes |
| Control mode | – | – | – | – | – | – | – | – | – | – | – | – | MIT force/position hybrid control |
| Joint backlash | – | – | – | – | – | – | – | – | – | – | – | – | <1° |
| Operating temperature | – | – | – | −20 to 60 °C | −20 to 60 °C | – | – | – | – | – | – | – | – |
| Transmission mechanism | – | – | – | 12 micro force-controlled composite-transmission joints plus 4 micro gear joints | 12 micro force-controlled composite-transmission joints plus 4 micro gear joints | – | – | – | – | – | – | – | Direct-drive rotary joints; backdrivable |
| Grasping configuration | – | – | – | – | – | – | – | Thumb lateral range >65° | – | – | – | – | Fully opposed; supports lateral swing |
| Wrist RGB camera included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Hand / end-effector notes | Two-finger force-controlled gripper; specifications are per gripper. | Three-finger force-controlled hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger force-controlled hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Five-finger dexterous hand; specifications are per hand. | Five-finger dexterous hand; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | – | Documented mass is approximately 800 g (790 g + 10 g); specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | Variant table identifies this Wuji Hand 2 configuration as non-tactile; specifications are per hand. |
| Package, Warranty & Notes | |||||||||||||
| Included items | Dex1-1 Plus grippers × 2; H2-A upper-body battery; charger; handheld remote controller | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2; H2-A upper-body battery; charger; handheld remote controller | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2; H2-A upper-body battery; charger; handheld remote controller | Dex5-1 force-controlled dexterous hands, non-tactile × 2; H2-A upper-body battery; charger; handheld remote controller | Dex5-1P force-controlled dexterous hands, tactile × 2; H2-A upper-body battery; charger; handheld remote controller | BrainCo Revo2 Basic bionic dexterous hands × 2; H2-A upper-body battery; charger; handheld remote controller | BrainCo Revo2 Touch tactile bionic dexterous hands × 2; H2-A upper-body battery; charger; handheld remote controller | Inspire DFQ dexterous hands, non-tactile × 2; H2-A upper-body battery; charger; handheld remote controller | Inspire E2 dexterous hands, tactile × 2; H2-A upper-body battery; charger; handheld remote controller | BrainCo Revo3 U21 dexterous hands, non-tactile × 2; H2-A upper-body battery; charger; handheld remote controller | BrainCo Revo3 U21T tactile dexterous hands × 2; H2-A upper-body battery; charger; handheld remote controller | BrainCo Revo3 U21VT visual-tactile dexterous hands × 2; H2-A upper-body battery; charger; handheld remote controller | Wuji Hand 2 dexterous hands, non-tactile × 2; H2-A upper-body battery; charger; handheld remote controller |
| Whole-unit warranty | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months |
| Warranty / option notes | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. |
| Additional specification notes | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. | Dimensions are stated as 780 × 444 × 200 mm. Weight includes the upper-body battery. |
| Configuration | H2-A Standard A, H2-A Standard B, H2-A Standard C, H2-A Standard D, H2-A Standard E, H2-A Standard F, H2-A Standard G, H2-A Standard H, H2-A Standard I, H2-A Standard J, H2-A Standard K, H2-A Standard L, H2-A Standard M |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid robot |
| Application | Research, Education, Development, Embodied AI, Manipulation |
The Unitree H2-A is a compact upper-body humanoid platform with 7 DoF per arm, a 3 DoF waist and a 2 DoF head.